ROS Controller Check Setting
Check Setting
Manipulator Description
- Jazzy
- Humble
- Noetic
- Arduino
Not supported.
Not supported.
NOTE:
Please launch the OpenMANIPULATOR-X Controller before running this section.
Publish a topic message to check the OpenMANIPULATOR-X setting.
$ rostopic pub /option std_msgs/String "print_open_manipulator_setting"
Manipulator Description will be printed on the terminal where the open_manipulator_controller is running.
Current configuration of the OpenMANIPULATOR-X is displayed.
Parameters related to the description is loaded from the open_manipulator.cpp in the open_manipulator_libs package.
~/catkin_ws/src/open_manipulator/open_manipulator_libs/src/open_manipulator.cpp
  ----------<Manipulator Description>----------
  <Degree of freedom>
  4.000
  <Size of Components>
  5.000

  <Configuration of world>
  [Name]
  -World Name : world
  -Child Name : joint1
  [Static Pose]
  -Position :
  (0.000, 0.000, 0.000)
  -Orientation :
  (1.000, 0.000, 0.000
  0.000, 1.000, 0.000
  0.000, 0.000, 1.000)
  [Dynamic Pose]
  -Linear Velocity :
  (0.000, 0.000, 0.000)
  -Linear acceleration :
  (0.000, 0.000, 0.000)
  -Angular Velocity :
  (0.000, 0.000, 0.000)
  -Angular acceleration :
  (0.000, 0.000, 0.000)

  <Configuration of gripper>
  [Component Type]
    Tool
  [Name]
  -Parent Name : joint4
  [Actuator]
  -Actuator Name : tool_dxl
  -ID :  15
  -Joint Axis :
  (0.000, 0.000, 0.000)
  -Coefficient :  -0.015
  -Limit :
      Maximum : 0.010, Minimum : -0.010
  [Actuator Value]
  -Value :  0.008
  -Velocity :  0.000
  -Acceleration :  0.000
  -Effort :  0.000
  [Constant]
  -Relative Position from parent component :
  (0.130, 0.000, 0.000)
  -Relative Orientation from parent component :
  (1.000, 0.000, 0.000
  0.000, 1.000, 0.000
  0.000, 0.000, 1.000)
  -Mass :  0.000
  -Inertia Tensor :
  (1.000, 0.000, 0.000
  0.000, 1.000, 0.000
  0.000, 0.000, 1.000)
  -Center of Mass :
  (0.000, 0.000, 0.000)
  [Variable]
  -Position :
  (0.138, -0.005, 0.015)
  -Orientation :
  (-0.006, 0.043, 0.999
  0.000, 0.999, -0.043
  -1.000, 0.000, -0.006)
  -Linear Velocity :
  (0.000, 0.000, 0.000)
  -Linear acceleration :
  (0.000, 0.000, 0.000)
  -Angular Velocity :
  (0.000, 0.000, 0.000)
  -Angular acceleration :
  (0.000, 0.000, 0.000)

  <Configuration of joint1>
  [Component Type]
    Active Joint
  [Name]
  -Parent Name : world
  -Child Name 1 : joint2
  [Actuator]
  -Actuator Name : joint_dxl
  -ID :  11
  -Joint Axis :
  (0.000, 0.000, 1.000)
  -Coefficient :  1.000
  -Limit :
      Maximum : 3.142, Minimum : -3.142
  [Actuator Value]
  -Value :  -0.043
  -Velocity :  0.000
  -Acceleration :  0.000
  -Effort :  0.000
  [Constant]
  -Relative Position from parent component :
  (0.012, 0.000, 0.017)
  -Relative Orientation from parent component :
  (1.000, 0.000, 0.000
  0.000, 1.000, 0.000
  0.000, 0.000, 1.000)
  -Mass :  0.000
  -Inertia Tensor :
  (1.000, 0.000, 0.000
  0.000, 1.000, 0.000
  0.000, 0.000, 1.000)
  -Center of Mass :
  (0.000, 0.000, 0.000)
  [Variable]
  -Position :
  (0.012, 0.000, 0.017)
  -Orientation :
  (0.999, 0.043, 0.000
  -0.043, 0.999, 0.000
  0.000, 0.000, 1.000)
  -Linear Velocity :
  (0.000, 0.000, 0.000)
  -Linear acceleration :
  (0.000, 0.000, 0.000)
  -Angular Velocity :
  (0.000, 0.000, 0.000)
  -Angular acceleration :
  (0.000, 0.000, 0.000)

  <Configuration of joint2>
  [Component Type]
    Active Joint
  [Name]
  -Parent Name : joint1
  -Child Name 1 : joint3
  [Actuator]
  -Actuator Name : joint_dxl
  -ID :  12
  -Joint Axis :
  (0.000, 1.000, 0.000)
  -Coefficient :  1.000
  -Limit :
      Maximum : 1.571, Minimum : -2.050
  [Actuator Value]
  -Value :  -0.052
  -Velocity :  0.000
  -Acceleration :  0.000
  -Effort :  0.000
  [Constant]
  -Relative Position from parent component :
  (0.000, 0.000, 0.058)
  -Relative Orientation from parent component :
  (1.000, 0.000, 0.000
  0.000, 1.000, 0.000
  0.000, 0.000, 1.000)
  -Mass :  0.000
  -Inertia Tensor :
  (1.000, 0.000, 0.000
  0.000, 1.000, 0.000
  0.000, 0.000, 1.000)
  -Center of Mass :
  (0.000, 0.000, 0.000)
  [Variable]
  -Position :
  (0.012, 0.000, 0.075)
  -Orientation :
  (0.998, 0.043, -0.052
  -0.043, 0.999, 0.002
  0.052, 0.000, 0.999)
  -Linear Velocity :
  (0.000, 0.000, 0.000)
  -Linear acceleration :
  (0.000, 0.000, 0.000)
  -Angular Velocity :
  (0.000, 0.000, 0.000)
  -Angular acceleration :
  (0.000, 0.000, 0.000)

  <Configuration of joint3>
  [Component Type]
    Active Joint
  [Name]
  -Parent Name : joint2
  -Child Name 1 : joint4
  [Actuator]
  -Actuator Name : joint_dxl
  -ID :  13
  -Joint Axis :
  (0.000, 1.000, 0.000)
  -Coefficient :  1.000
  -Limit :
      Maximum : 1.530, Minimum : -1.571
  [Actuator Value]
  -Value :  0.546
  -Velocity :  0.000
  -Acceleration :  0.000
  -Effort :  0.000
  [Constant]
  -Relative Position from parent component :
  (0.024, 0.000, 0.128)
  -Relative Orientation from parent component :
  (1.000, 0.000, 0.000
  0.000, 1.000, 0.000
  0.000, 0.000, 1.000)
  -Mass :  0.000
  -Inertia Tensor :
  (1.000, 0.000, 0.000
  0.000, 1.000, 0.000
  0.000, 0.000, 1.000)
  -Center of Mass :
  (0.000, 0.000, 0.000)
  [Variable]
  -Position :
  (0.029, -0.001, 0.204)
  -Orientation :
  (0.880, 0.043, 0.474
  -0.038, 0.999, -0.020
  -0.474, 0.000, 0.880)
  -Linear Velocity :
  (0.000, 0.000, 0.000)
  -Linear acceleration :
  (0.000, 0.000, 0.000)
  -Angular Velocity :
  (0.000, 0.000, 0.000)
  -Angular acceleration :
  (0.000, 0.000, 0.000)

  <Configuration of joint4>
  [Component Type]
    Active Joint
  [Name]
  -Parent Name : joint3
  -Child Name 1 : gripper
  [Actuator]
  -Actuator Name : joint_dxl
  -ID :  14
  -Joint Axis :
  (0.000, 1.000, 0.000)
  -Coefficient :  1.000
  -Limit :
      Maximum : 2.000, Minimum : -1.800
  [Actuator Value]
  -Value :  1.083
  -Velocity :  0.000
  -Acceleration :  0.000
  -Effort :  -2.690
  [Constant]
  -Relative Position from parent component :
  (0.124, 0.000, 0.000)
  -Relative Orientation from parent component :
  (1.000, 0.000, 0.000
  0.000, 1.000, 0.000
  0.000, 0.000, 1.000)
  -Mass :  0.000
  -Inertia Tensor :
  (1.000, 0.000, 0.000
  0.000, 1.000, 0.000
  0.000, 0.000, 1.000)
  -Center of Mass :
  (0.000, 0.000, 0.000)
  [Variable]
  -Position :
  (0.138, -0.005, 0.145)
  -Orientation :
  (-0.006, 0.043, 0.999
  0.000, 0.999, -0.043
  -1.000, 0.000, -0.006)
  -Linear Velocity :
  (0.000, 0.000, 0.000)
  -Linear acceleration :
  (0.000, 0.000, 0.000)
  -Angular Velocity :
  (0.000, 0.000, 0.000)
  -Angular acceleration :
  (0.000, 0.000, 0.000)
  ---------------------------------------------
Not supported
RViz
- Jazzy
- Humble
- Noetic
- Arduino
WARNING: Before running RViz, make sure to terminate all controller nodes including the bringup and other nodes that were previously running.
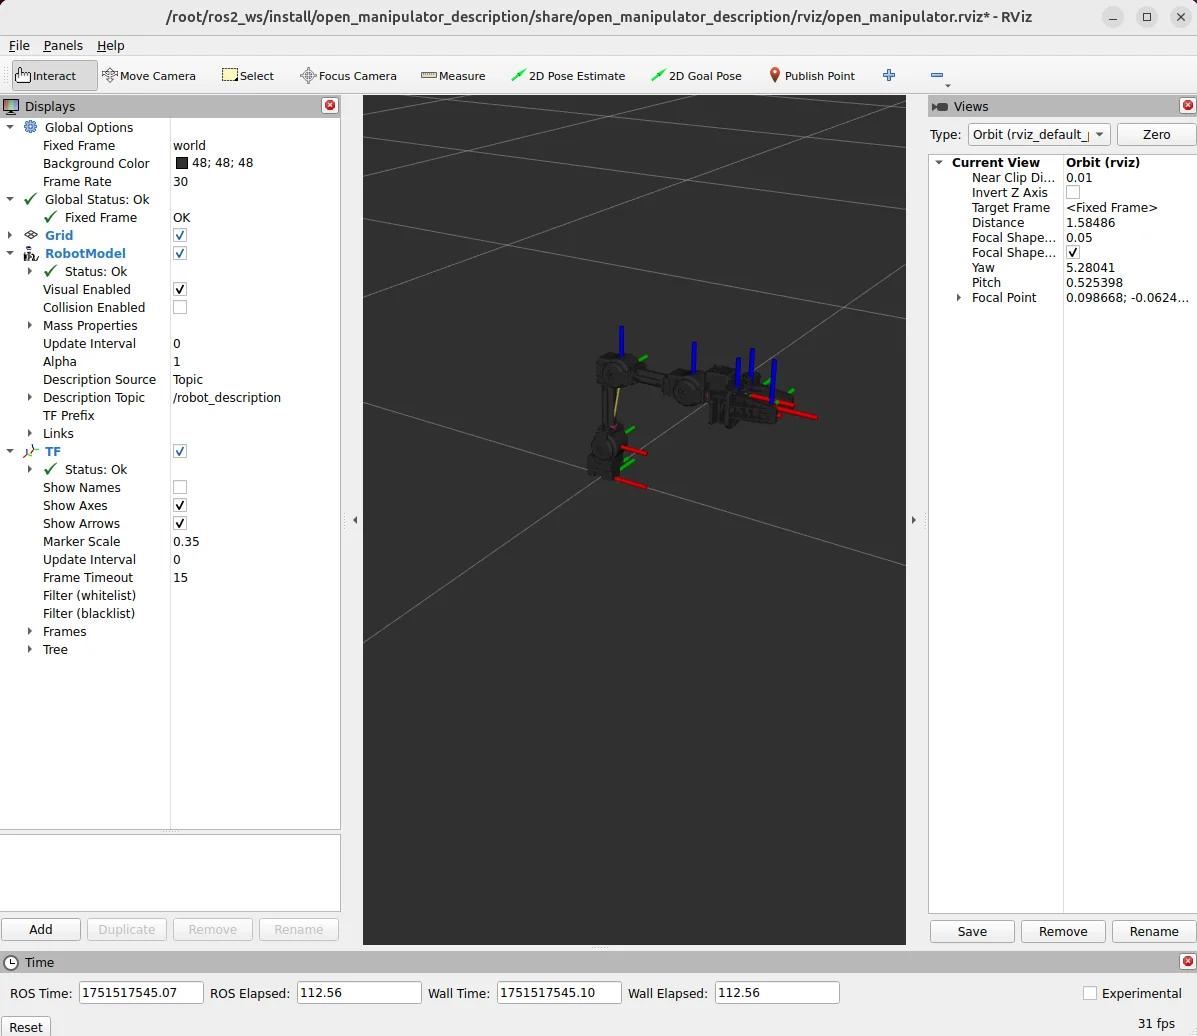
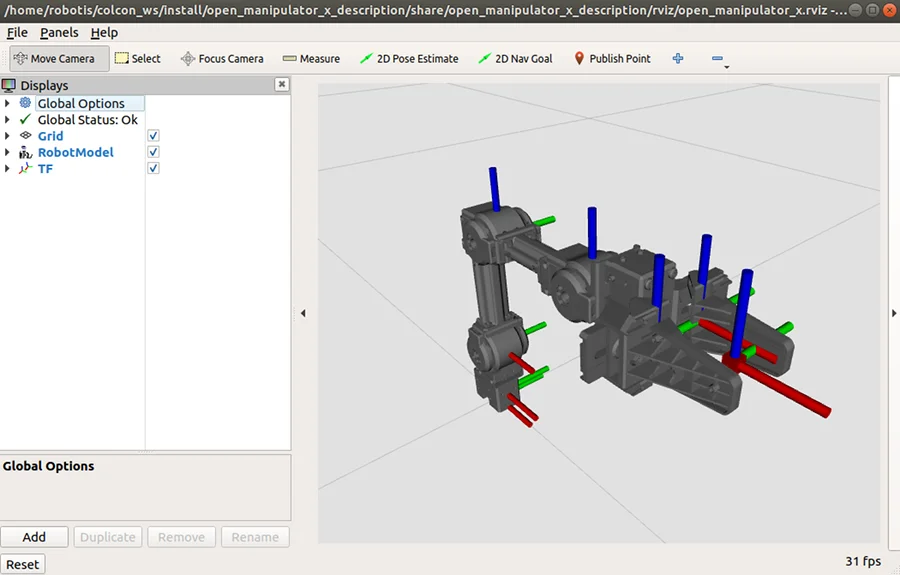
Load OpenMANIPULATOR-X on RViz.
$ ros2 launch open_manipulator_description open_manipulator_x.launch.py
Load OpenMANIPULATOR-X on RViz.
$ ros2 launch open_manipulator_x_description model.launch.py
NOTE:
Please launch the OpenMANIPULATOR-X Controller before running this section.
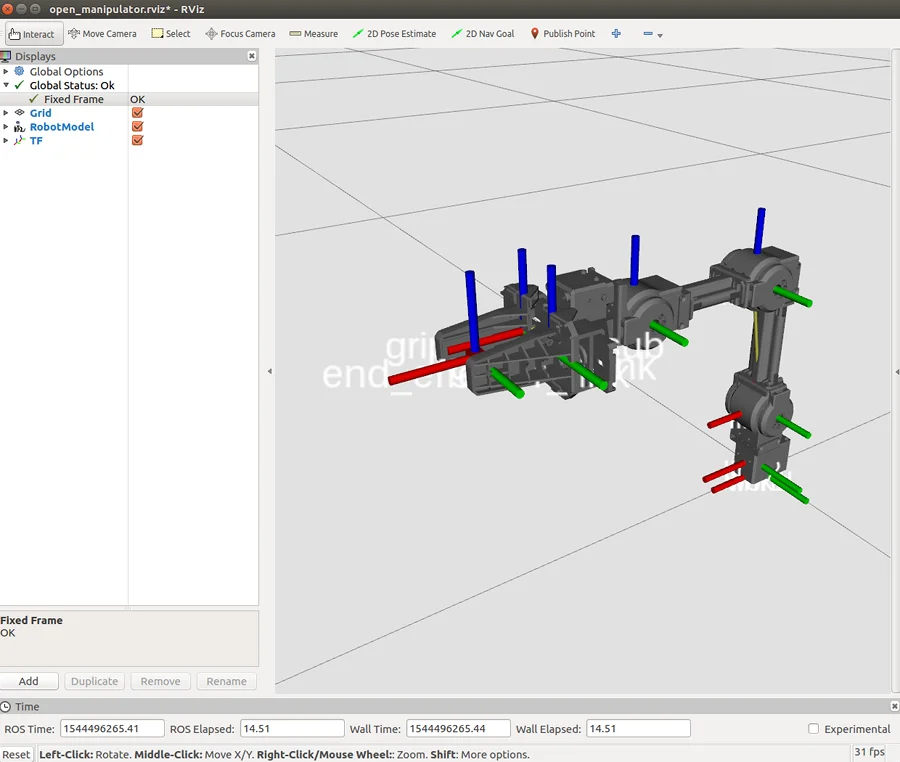
Load OpenMANIPULATOR-X on RViz.
$ roslaunch open_manipulator_description open_manipulator_rviz.launch
NOTE:
- If the OpenMANIPULATOR-X controller is running when the RViz is launched, the robot model on RViz will be synchronized with the actual pose of OpenMANIPULATOR-X.
- Installing the joint_state_publisher_gui package allows to simply test the OpenMANIPULATOR-X model. Make sure to install the package and launch the RViz with additional option.
- Install the joint_state_publisher_gui
$ sudo apt-get install ros-noetic-joint-state-publisher-gui- Launch the RViz with the GUI option
$ roslaunch open_manipulator_description open_manipulator_rviz.launch use_gui:=true
Not supported