Software Overview
OMX is a 5-DOF robotic manipulator designed for real-world Physical AI research.
It supports teleoperation, trajectory learning, and deployment of AI policies through a unified ROS 2 control architecture.
The platform runs on ROS 2 Jazzy and uses the ros2_control framework for real-time joint-level control.
The arm is driven by DYNAMIXEL-X series actuators connected over TTL using the Dynamixel SDK.
This system is designed for:
- Collecting motion data through teleoperation
- Training and testing trajectory-based AI models
- Running learned or predefined trajectories on real hardware
OMX provides an efficient and compact platform for Physical AI research in both academic and industrial environments.
System Architecture
The diagram below illustrates the overall control structure of OMX.
Teleoperation or AI-generated commands are processed through ros2_control, translated by the hardware interface, and executed by DYNAMIXEL actuators via TTL.
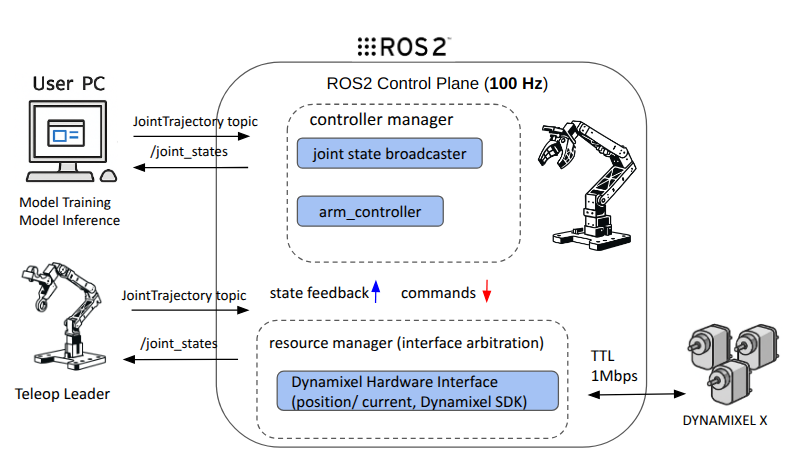
| Layer | Component | Description |
|---|---|---|
| Compute | User PC | ROS 2 Jazzy |
| Motion Control | ros2_control | joint control at 100Hz |
| Actuators | DYNAMIXEL-X series | servo via TTL |
| Communication | TTL | Dynamixel Protocol 2.0 |
Why ros2_control?
OMX uses ros2_control for modular, real-time control of its joints.
- Clean separation between hardware and control logic
- Supports multiple controller types (trajectory, GPIO, command)
- Integrates easily with teleop, GUI, and AI-based trajectory sources
This makes it easy to switch between manual, scripted, or learned motion strategies.
Motion Execution Pipeline
Input Source (Teleoperation / AI Policy)
      ↓
ROS 2 JointTrajectory / Command Topics
      ↓
controller_manager (100Hz loop)
      ↓
OMX Controllers
      ↓
DynamixelHardwareInterface
      ↓
TTL Bus
      ↓
DYNAMIXEL-X Actuators
Controller Configuration & Joint Mapping
| Controller | Segment | DOF | Input Topic |
|---|---|---|---|
arm_controller | 5-DOF Arm | 5(6) | /leader/arm_controller/joint_trajectory |
gpio_command_controller | Gripper (GPIO pin) | 1 | /gpio_command_controller/commands |
joint_command_broadcaster | All joints (read-only) | – | Publishes to /joint_states |
In AI TELEOPERATION mode, the number of joints in the Arm Controller becomes 6.
- The gripper operates in current-based position mode; all other actuators operate in position mode by default.
Controller YAML Example (link)
/**:
  controller_manager:
    ros__parameters:
      update_rate: 100  # Hz

      joint_state_broadcaster:
        type: joint_state_broadcaster/JointStateBroadcaster

      arm_controller:
        type: joint_trajectory_controller/JointTrajectoryController

/**:
  arm_controller:
    ros__parameters:
      joints:
        - joint1
        - joint2
        - joint3
        - joint4
        - joint5
        - gripper_joint_1

      interface_name: position

      command_interfaces:
        - position

      state_interfaces:
        - position
        - velocity

      allow_partial_joints_goal: true
Debugging & Visualization Tools
| Tool / Topic | Description |
|---|---|
ros2 control list_controllers | Check controller status |
ros2 topic echo /joint_states | Monitor joint position/velocity |
| Rviz2 | 3D view of robot model (URDF), TF, and movement |
Safety & Limits
- Joint limits are defined in the URDF and enforced at the controller layer
- Velocity/position clamping can be configured per joint
- Communication errors are detected by the Dynamixel hardware interface