Simulation
Overview
The OMX simulation environment is designed to test and validate robot functionalities in a controlled virtual setting. This allows for comprehensive evaluation of its capabilities across a variety of tasks before deployment on the physical hardware. The simulation ecosystem leverages industry-standard tools including ROS 2 providing diverse options for development and research.
Available Simulation Models and Environments
OMX models are available in URDF for Gazebo/RViz and MJCF for MuJoCo, providing the robot arm and gripper for testing and visualization.
Gazebo / RViz (URDF/SDF)
For seamless integration with the ROS ecosystem, a URDF (Unified Robot Description Format) model is provided. This is primarily used with Gazebo for physics simulation and RViz for 3D visualization of robot states and sensor data.
- Model Format: URDF
- Primary Tools: Gazebo Sim, RViz
- Purpose: General robotics simulation, ROS-based algorithm testing, visualization.
- Link: OMX URDF on GitHub
MuJoCo (MJCF)
The OMX MuJoCo model is included in open_manipulator_description/mujoco/omx and uses the description package's mesh assets.
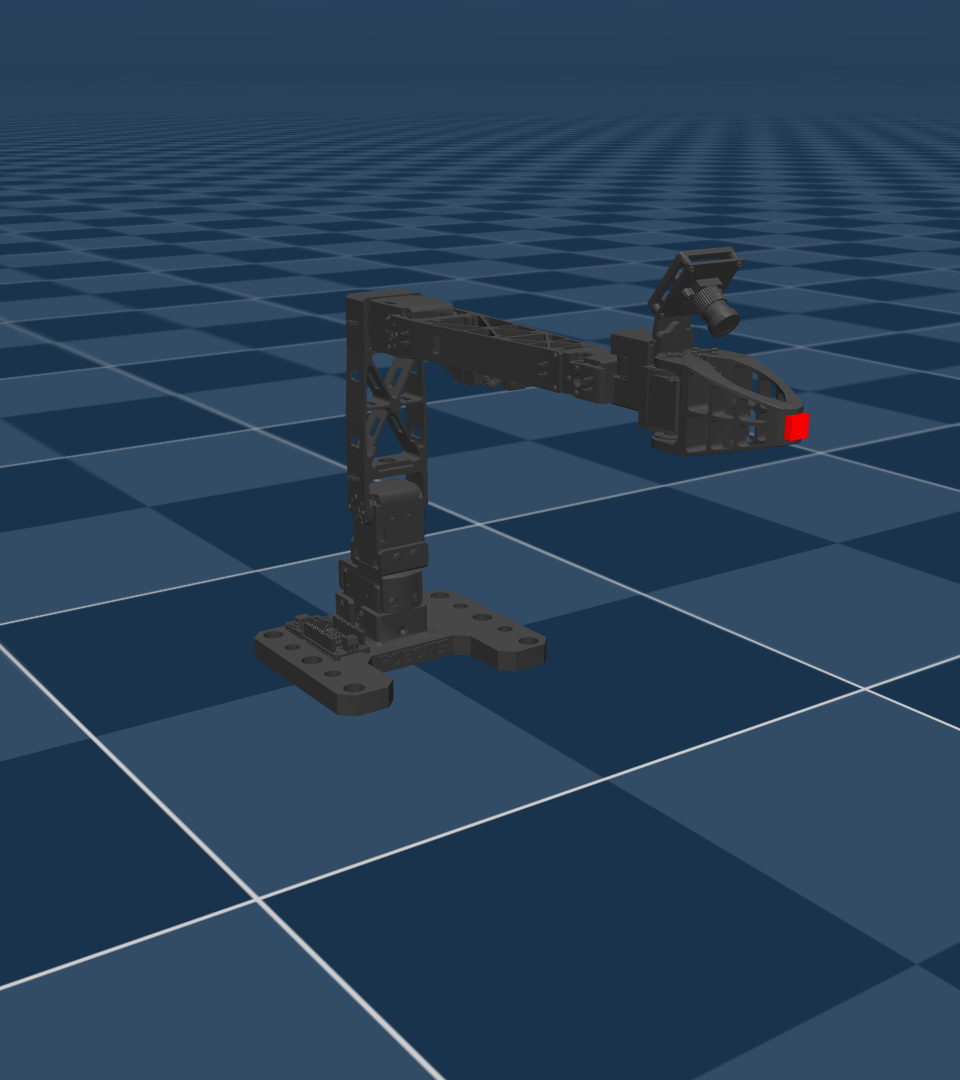
- Model Format: MJCF
- Primary Tool: MuJoCo
- Link: OMX MJCF on GitHub