Simulation
Overview
The ROBOTIS Hand simulation environment is designed to test and validate robot functionalities in a controlled virtual setting. This allows for comprehensive evaluation of its capabilities across a variety of tasks before deployment on the physical hardware. The simulation ecosystem leverages industry-standard tools including ROS 2 providing diverse options for development and research.
Available Simulation Models and Environments
The ROBOTIS Hand can be simulated in various environments using different model formats. These models describe the palm and articulated fingers of the ROBOTIS Hand, allowing for comprehensive testing.
Gazebo / RViz (URDF/SDF)
For seamless integration with the ROS ecosystem, URDF (Unified Robot Description Format) and SDF (Simulation Description Format) models are provided. These are primarily used with Gazebo for physics simulation and RViz for 3D visualization of robot states and sensor data.
- HX5-D20
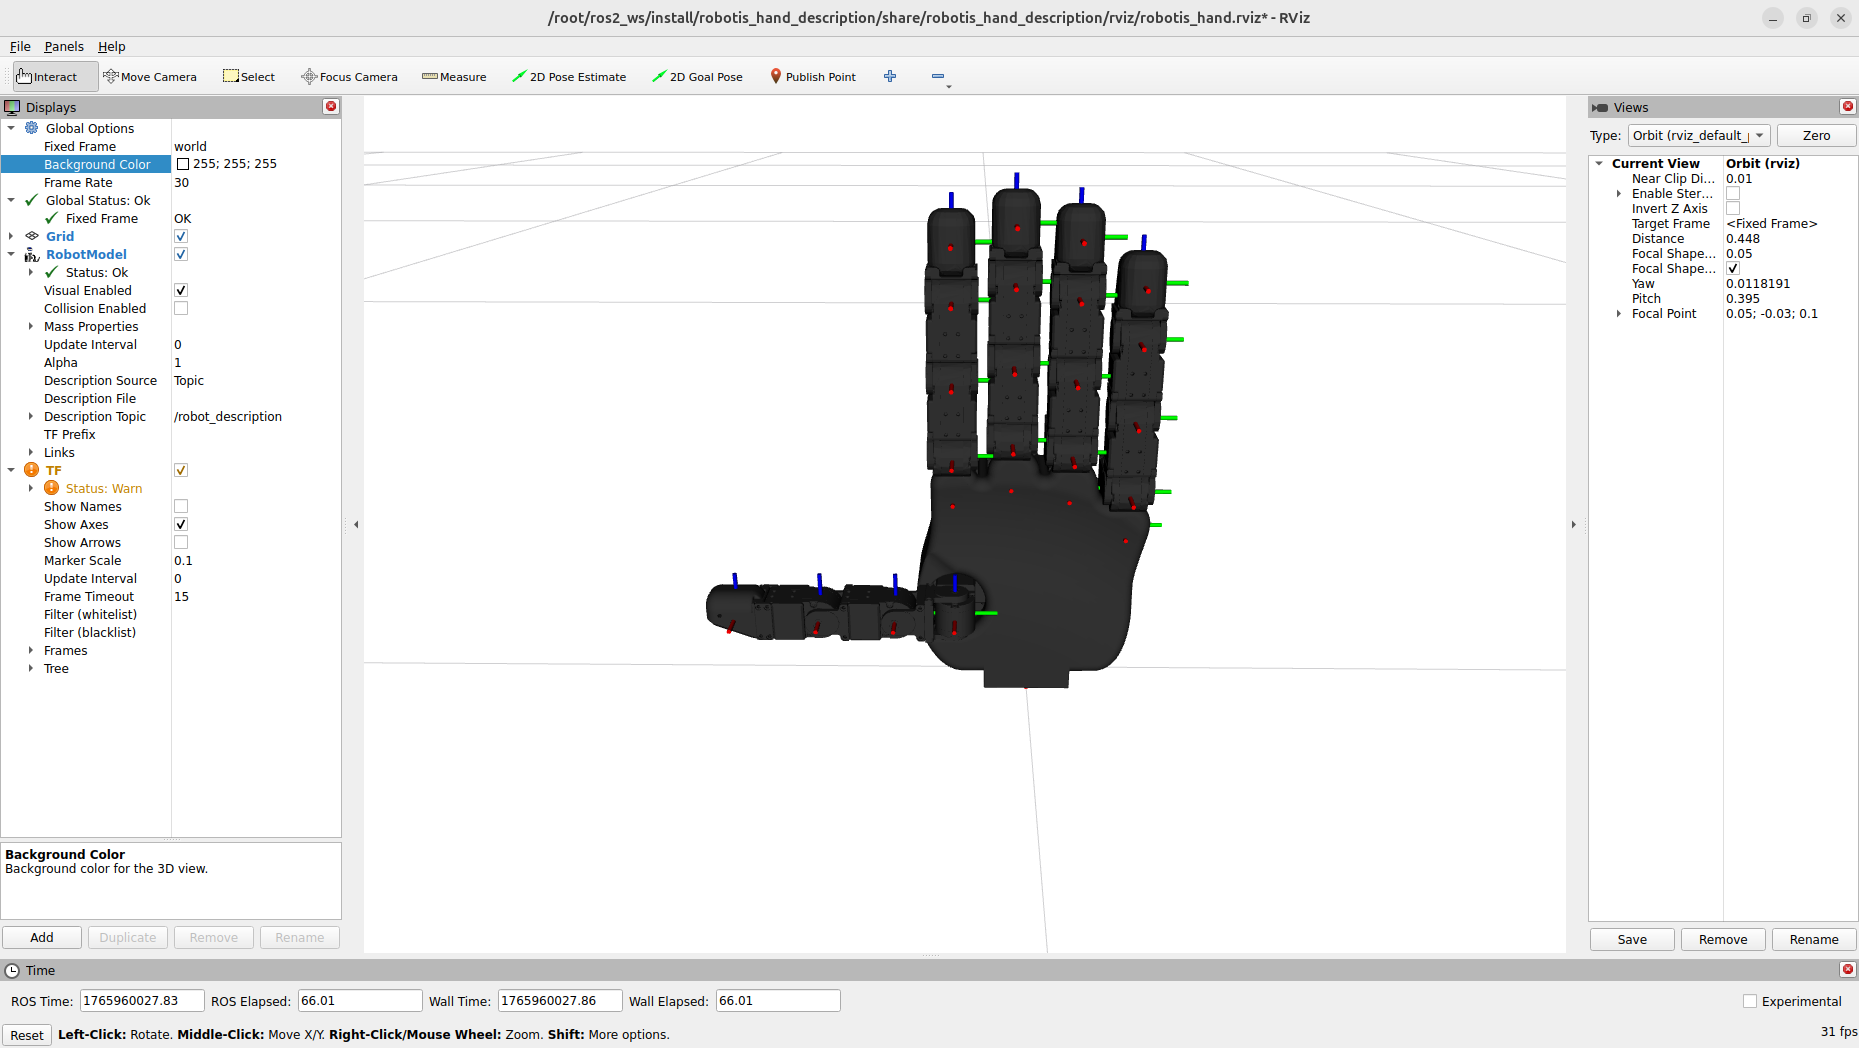
- Model Formats: URDF, SDF
- Primary Tools: Gazebo Sim, RViz
- Purpose: General robotics simulation, ROS-based algorithm testing, visualization.
- Link: ROBOTIS Hand URDF on GitHub
MuJoCo (MJCF)
HX5-D20 rev2 MuJoCo models are included in robotis_hand_description/mujoco/hx5_d20_rev2 and use the description package's mesh assets.
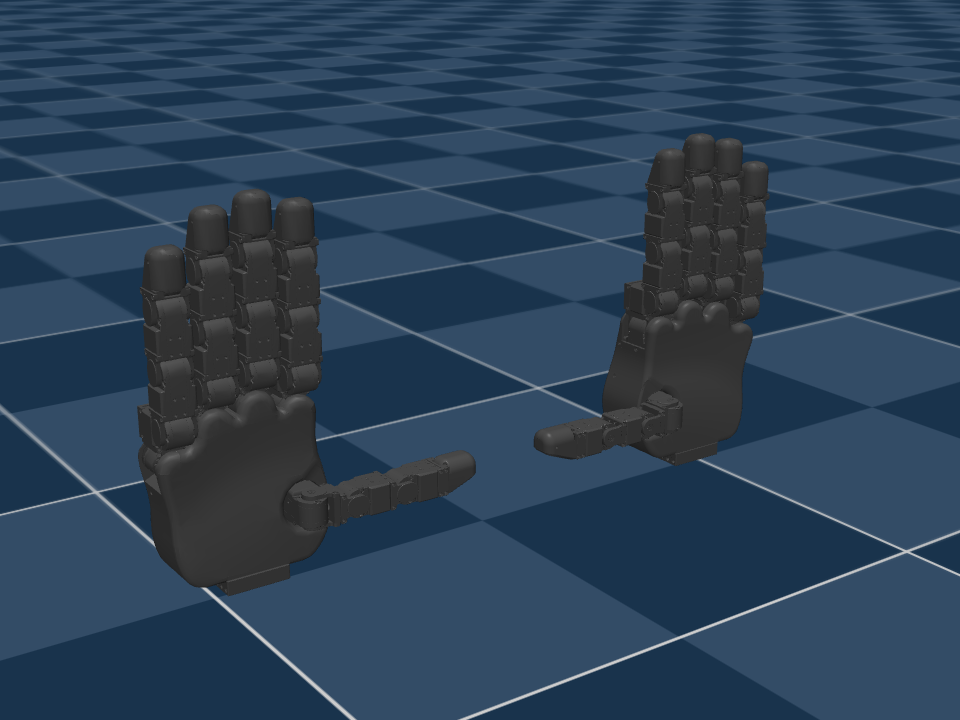
- Model Format: MJCF
- Primary Tool: MuJoCo
- Scenes:
scene_left.xml(left hand),scene_right.xml(right hand), andscene.xml(both hands). - Link: ROBOTIS Hand MJCF on GitHub