Community Showcase
: Inspiring Projects from Our Users
The DYNAMIXEL ecosystem thrives on the creativity and innovation of our users. We are thrilled to showcase some of the remarkable open-source projects developed by talented individuals, top universities, and pioneering companies around the world. These projects demonstrate the versatile capabilities of DYNAMIXEL actuators and how they empower developers to push the boundaries of robotics.
Discover how your peers are leveraging DYNAMIXEL technology to build the future, one groundbreaking project at a time. Many of these incredible advancements are proudly Powered by DYNAMIXEL.
Humanoids & Legged Robots
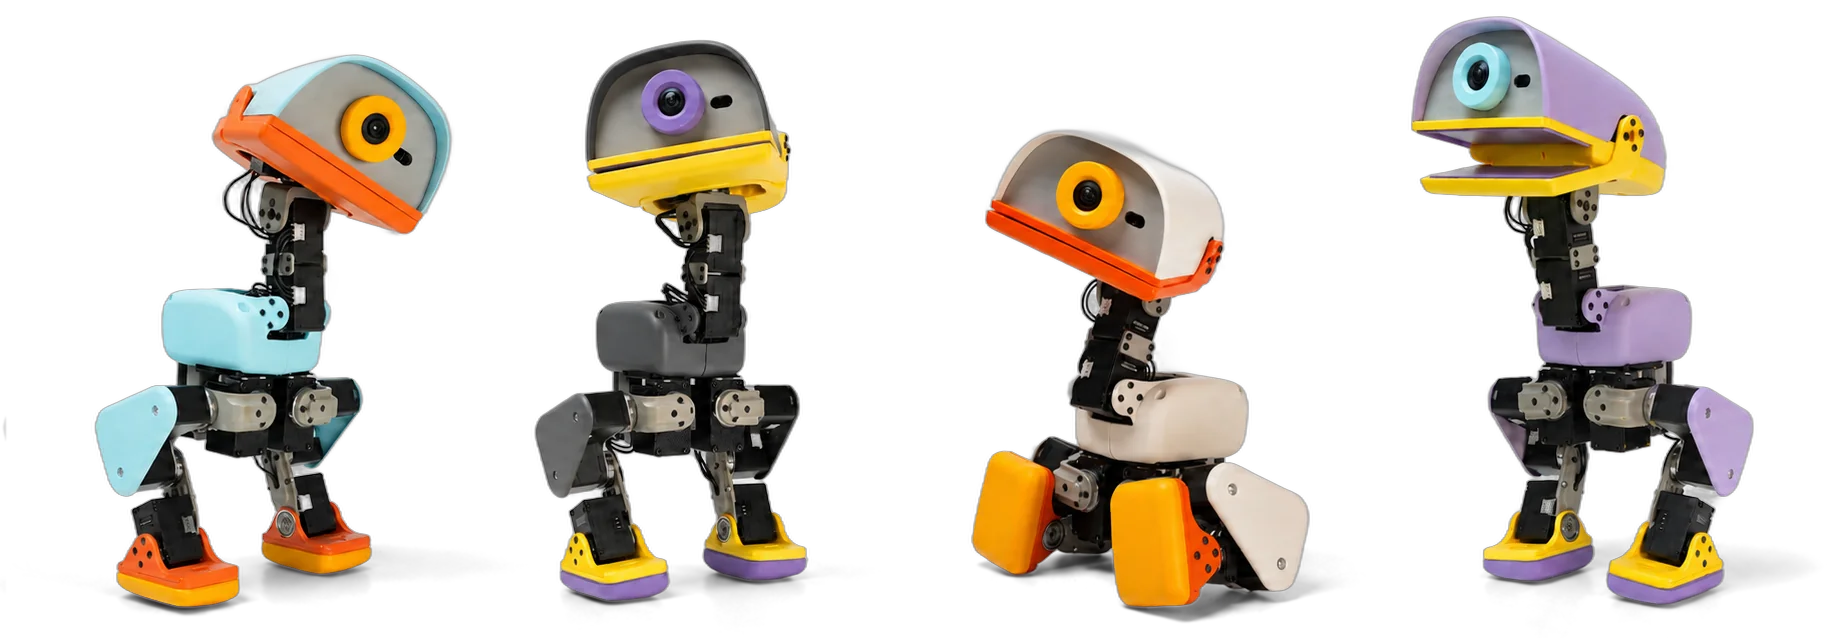
Micro Duck
Developed by: Pollen Robotics
Microduck is a 25 cm biped robot with fifteen DYNAMIXEL actuators. Its open-source software and reinforcement learning stack let users train behaviors in simulation and deploy them on the robot.
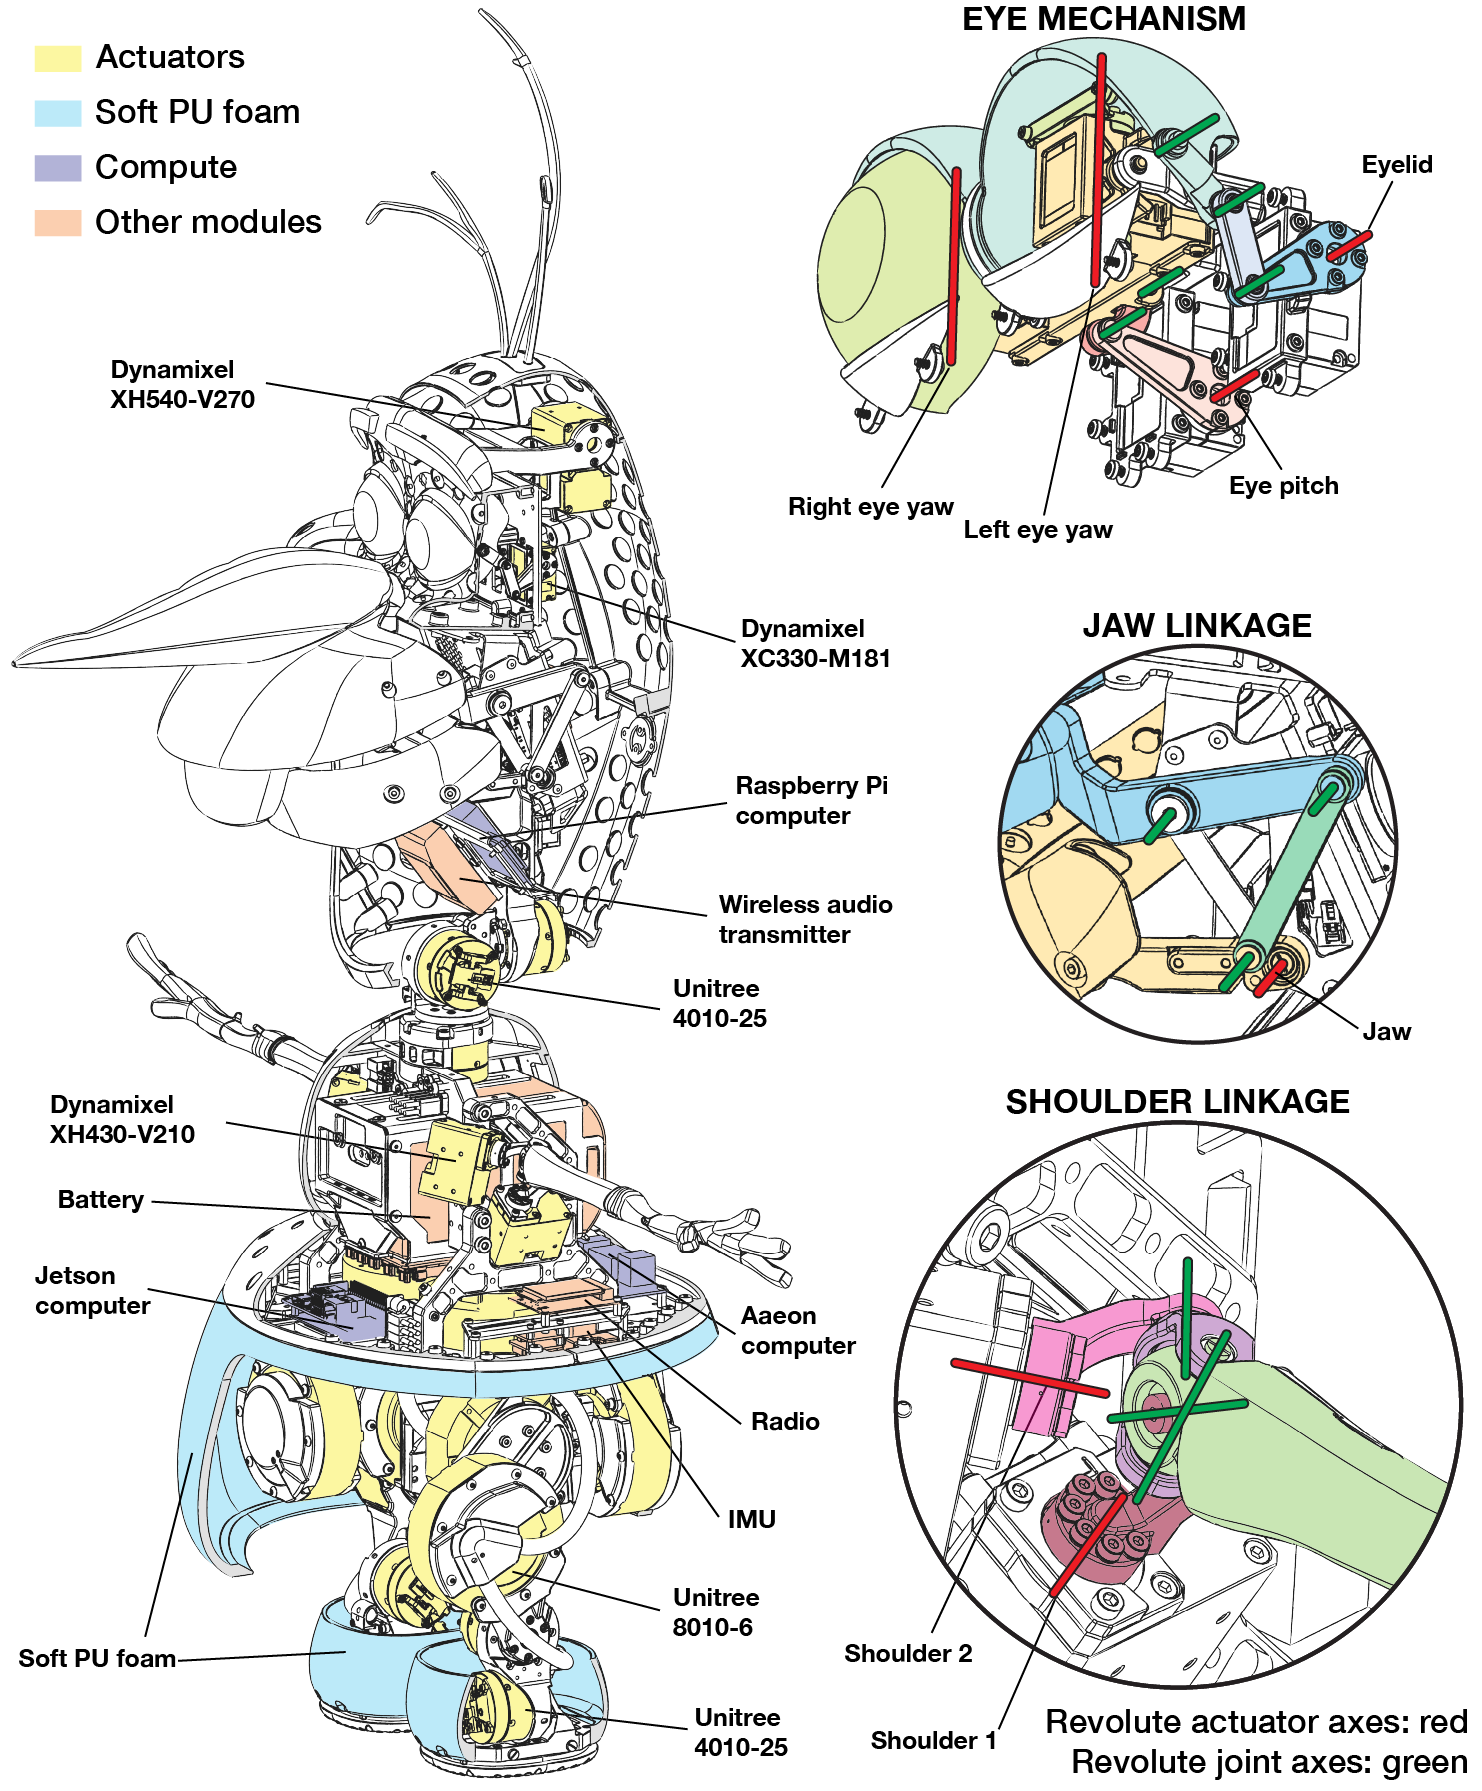
Olaf Robot
Developed by: Walt Disney Imagineering
Disney Imagineering's physical Olaf robot, controlled with RL using animation references. It uses DYNAMIXEL XH540-V270, XH430-V210, and XC330-M181 actuators.
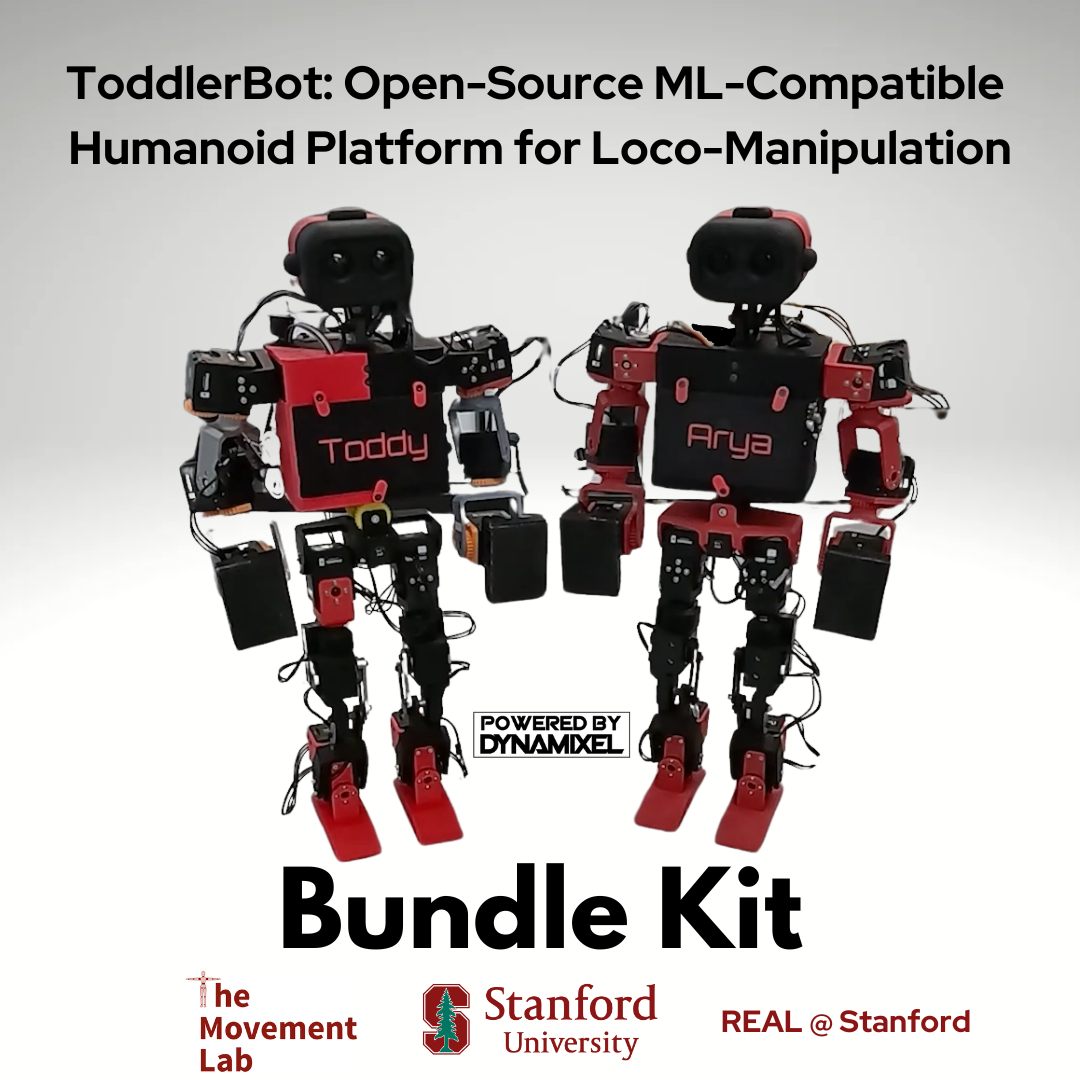
ToddlerBot
Developed by: Stanford University
An open-source humanoid platform for learning locomotion and manipulation. Its DYNAMIXEL-based design supports reinforcement learning, imitation learning, teleoperation, and deployment of learned whole-body behaviors.
Robotic Hands & Grippers
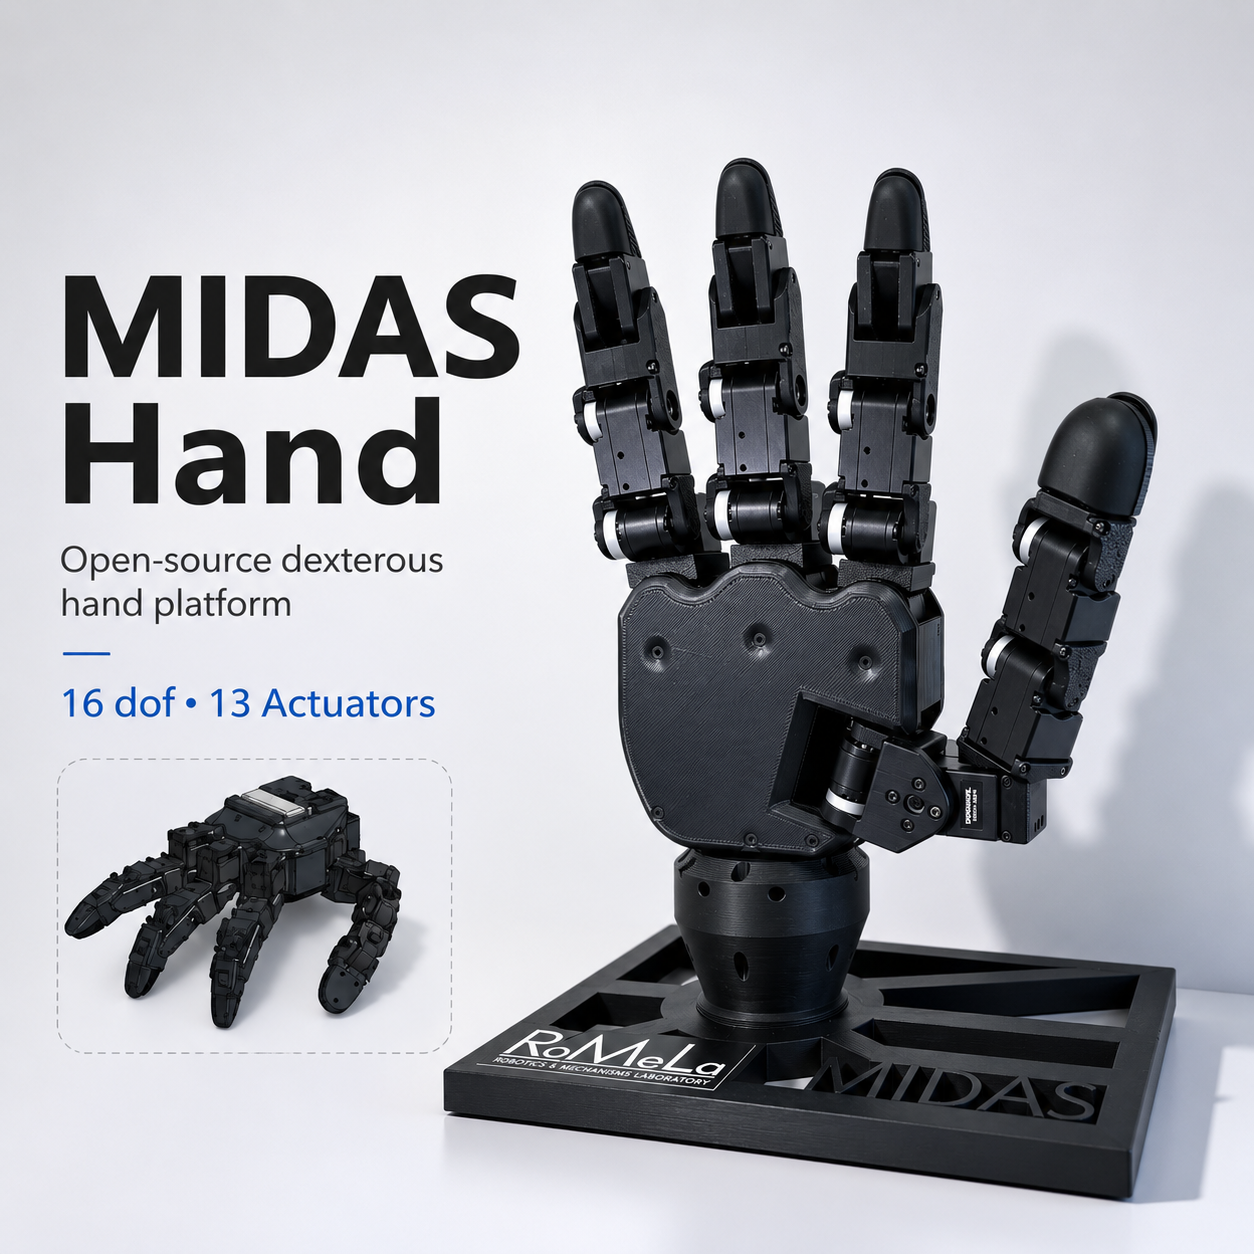
MIDAS Hand
Developed by: UCLA Robotics & Mechanisms Laboratory (RoMeLa)
An open-source anthropomorphic hand for dexterous manipulation and sensing research. Its 16-DOF architecture uses thirteen DYNAMIXEL XM335-T323-T actuators.
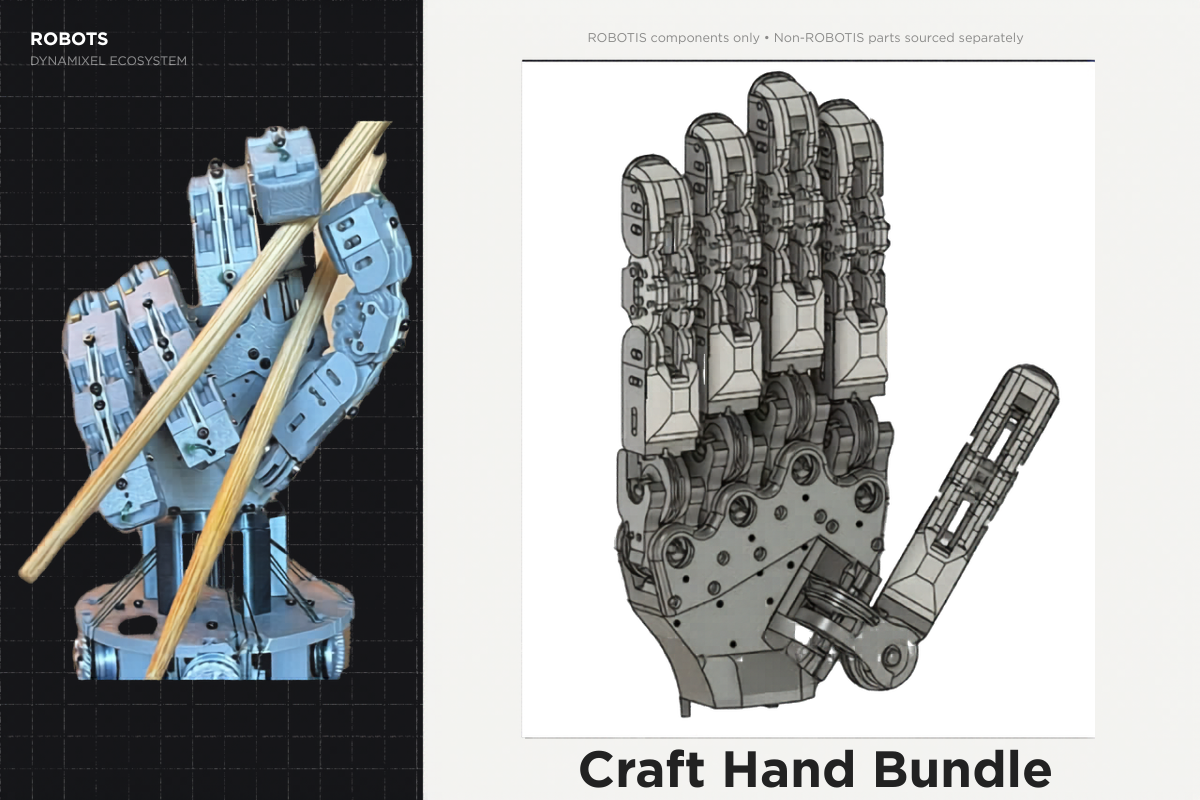
CRAFT Hand
Developed by: University of Illinois Urbana-Champaign, University of California Irvine
A tendon-driven anthropomorphic hand combining rigid links and soft joints for compliant, dexterous manipulation. It uses fifteen DYNAMIXEL XL330-M288-T actuators.
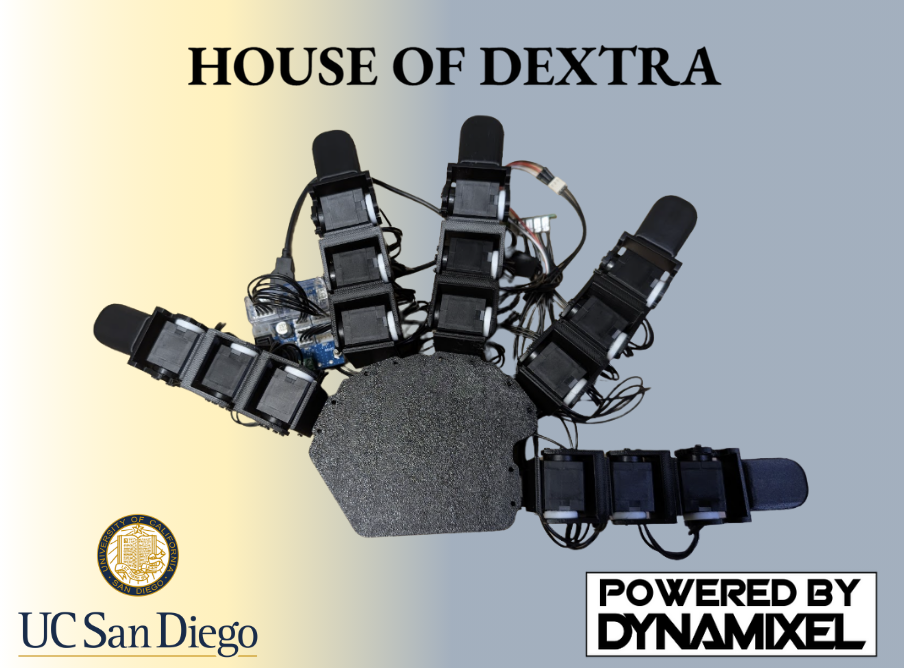
House of Dextra
Developed by: University of California San Diego, University of California Santa Barbara
An open-source framework that jointly optimizes robotic hand designs and control policies. Its modular hardware supports different finger counts, joint configurations, and palm shapes using DYNAMIXEL XL330-M288-T actuators.
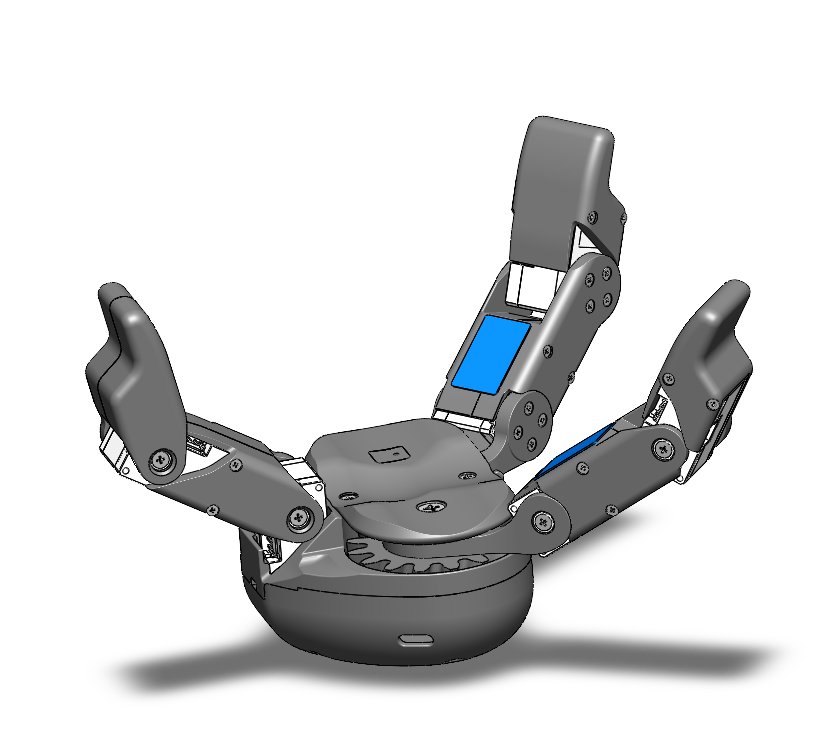
EN02-OP
Developed by: Westwood Robotics
A high-performance, open-source robotic hand designed for advanced manipulation tasks, utilizing DYNAMIXELs for precise control.
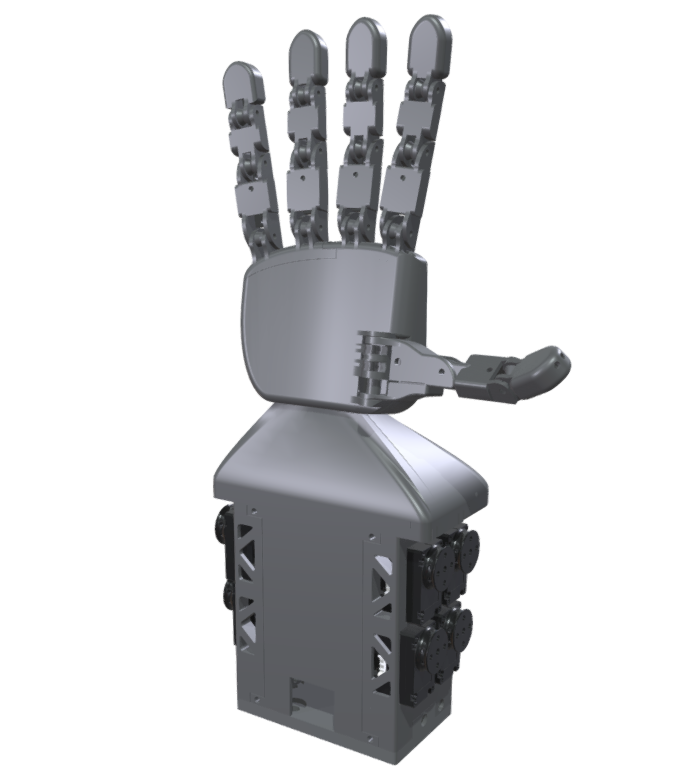
Ruka-Hand
Developed by: New York University
An open-source, 3D-printable robotic hand designed for accessibility and research, often built with DYNAMIXEL actuators.
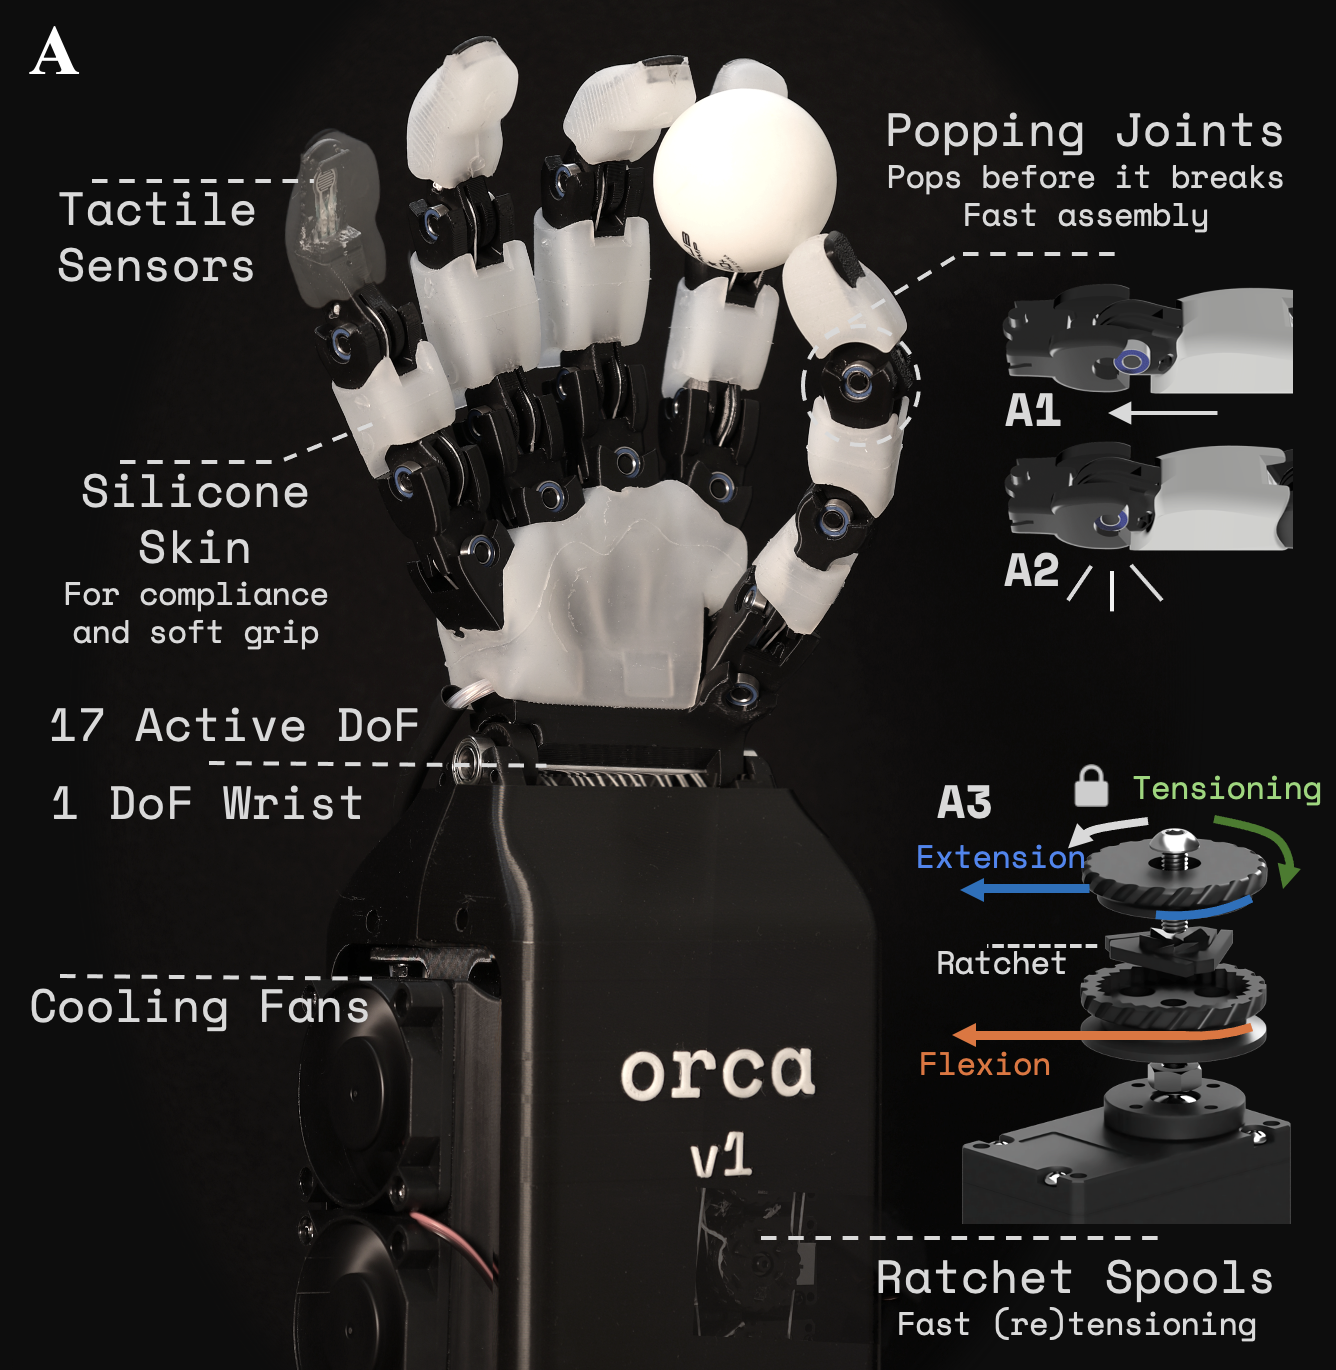
Orca Hand
Developed by: ETH Zurich
A modular and powerful open-source robotic hand for dexterous manipulation, showcasing the capabilities of DYNAMIXELs.
LeapHand
Developed by: Carnegie Mellon University
A low-cost, highly capable, and open-source anthropomorphic robotic hand, often integrating DYNAMIXEL actuators.
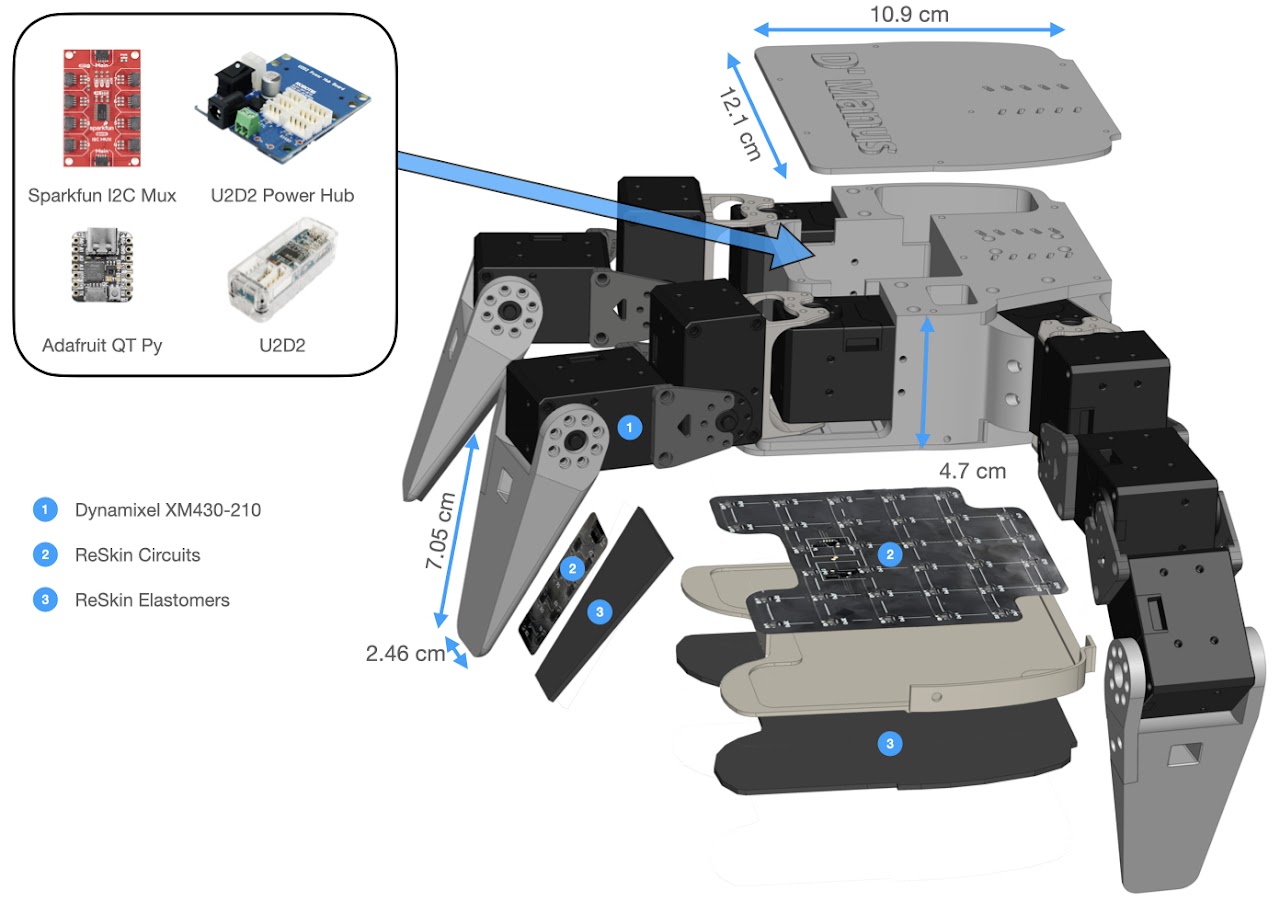
D’Manus
Developed by: Carnegie Mellon University, Meta AI (FAIR)
An open-source, three-fingered, 10-DOF robotic hand for dexterous manipulation and robot learning. DYNAMIXEL XM430 actuators drive its joints, while ReSkin sensors on the palm and fingertips provide tactile feedback for tasks such as picking and sorting objects.
D’Claw
Developed by: ROBEL Research Team
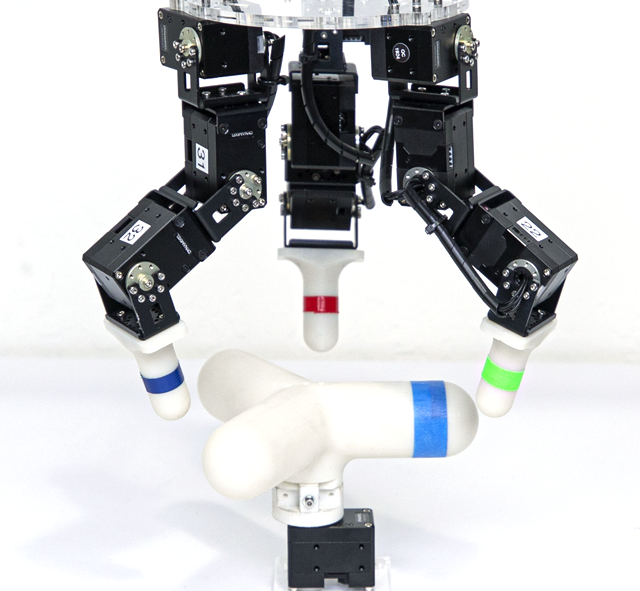
A three-fingered, nine-DOF manipulation platform from ROBEL. Its DYNAMIXEL actuators support real-world reinforcement learning experiments such as turning objects, grasping, and coordinating finger motions.
OpenHand
Developed by: Yale University
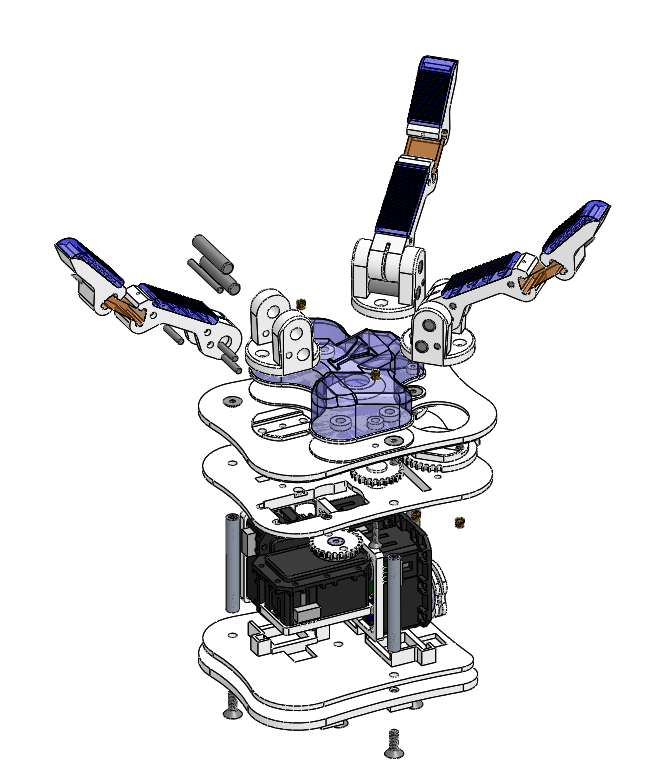
A project focusing on open-source, customizable, and accessible robotic hand designs, with DYNAMIXELs as a common choice for actuation.
Robot Arms & Bimanual Systems
TRLC-DK1
Developed by: The Robot Learning Company
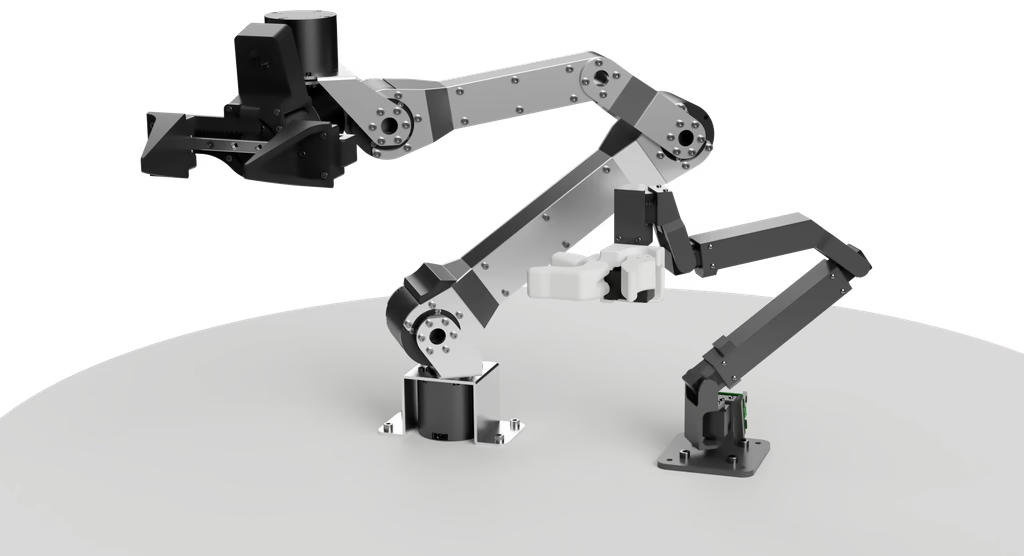
An open source dev kit for AI-native robotics. The leader arm uses seven DYNAMIXEL XL330-M077-T actuators.
Teleoperation & Demonstration Devices
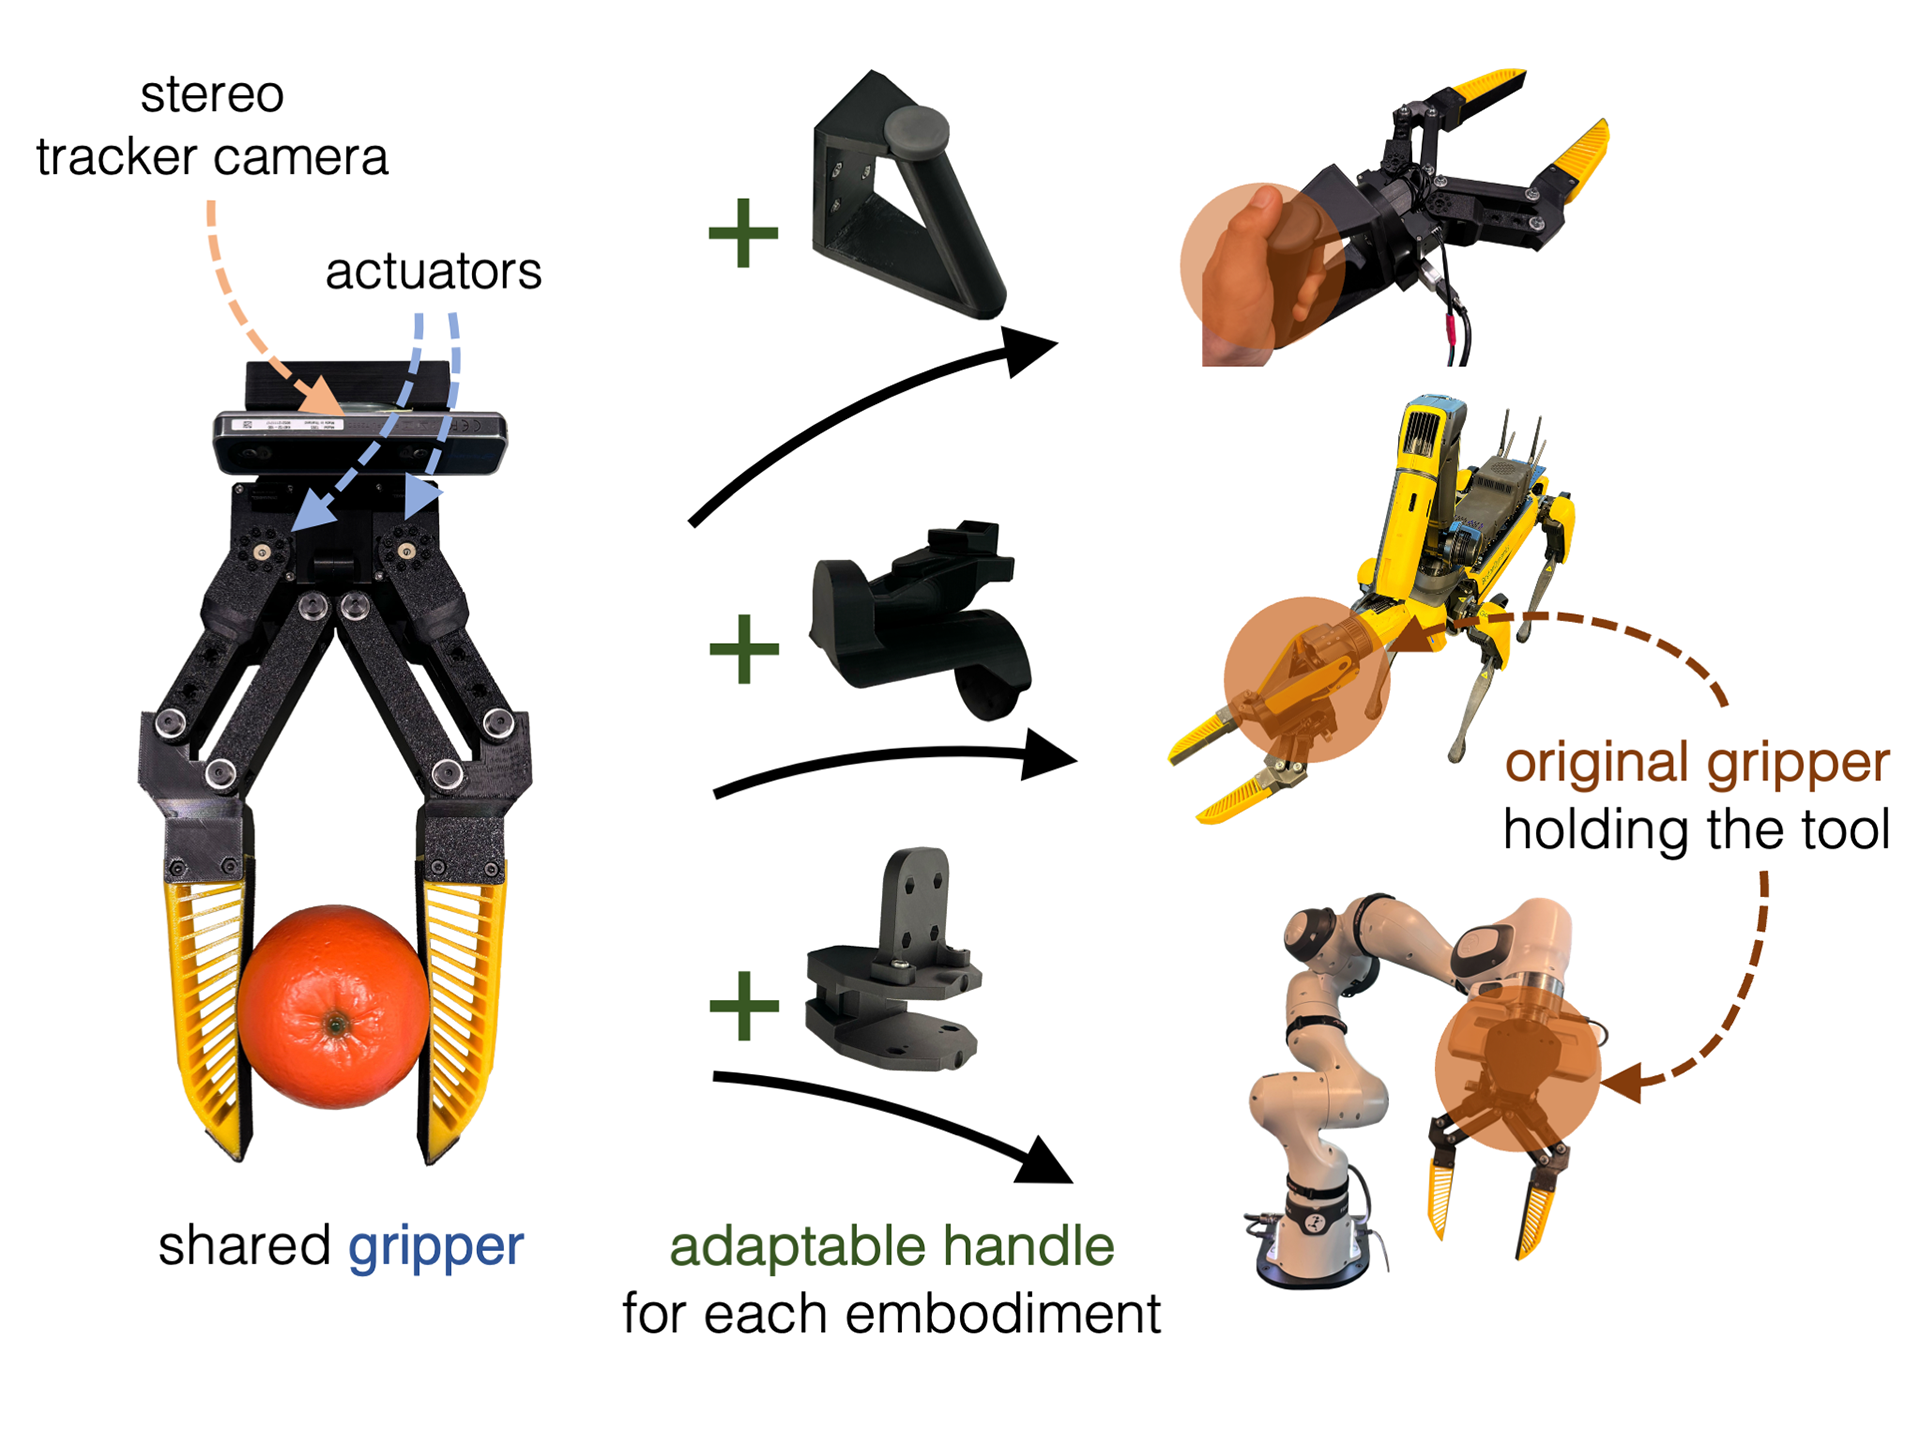
LEGATO
Developed by: The University of Texas at Austin, The AI Institute
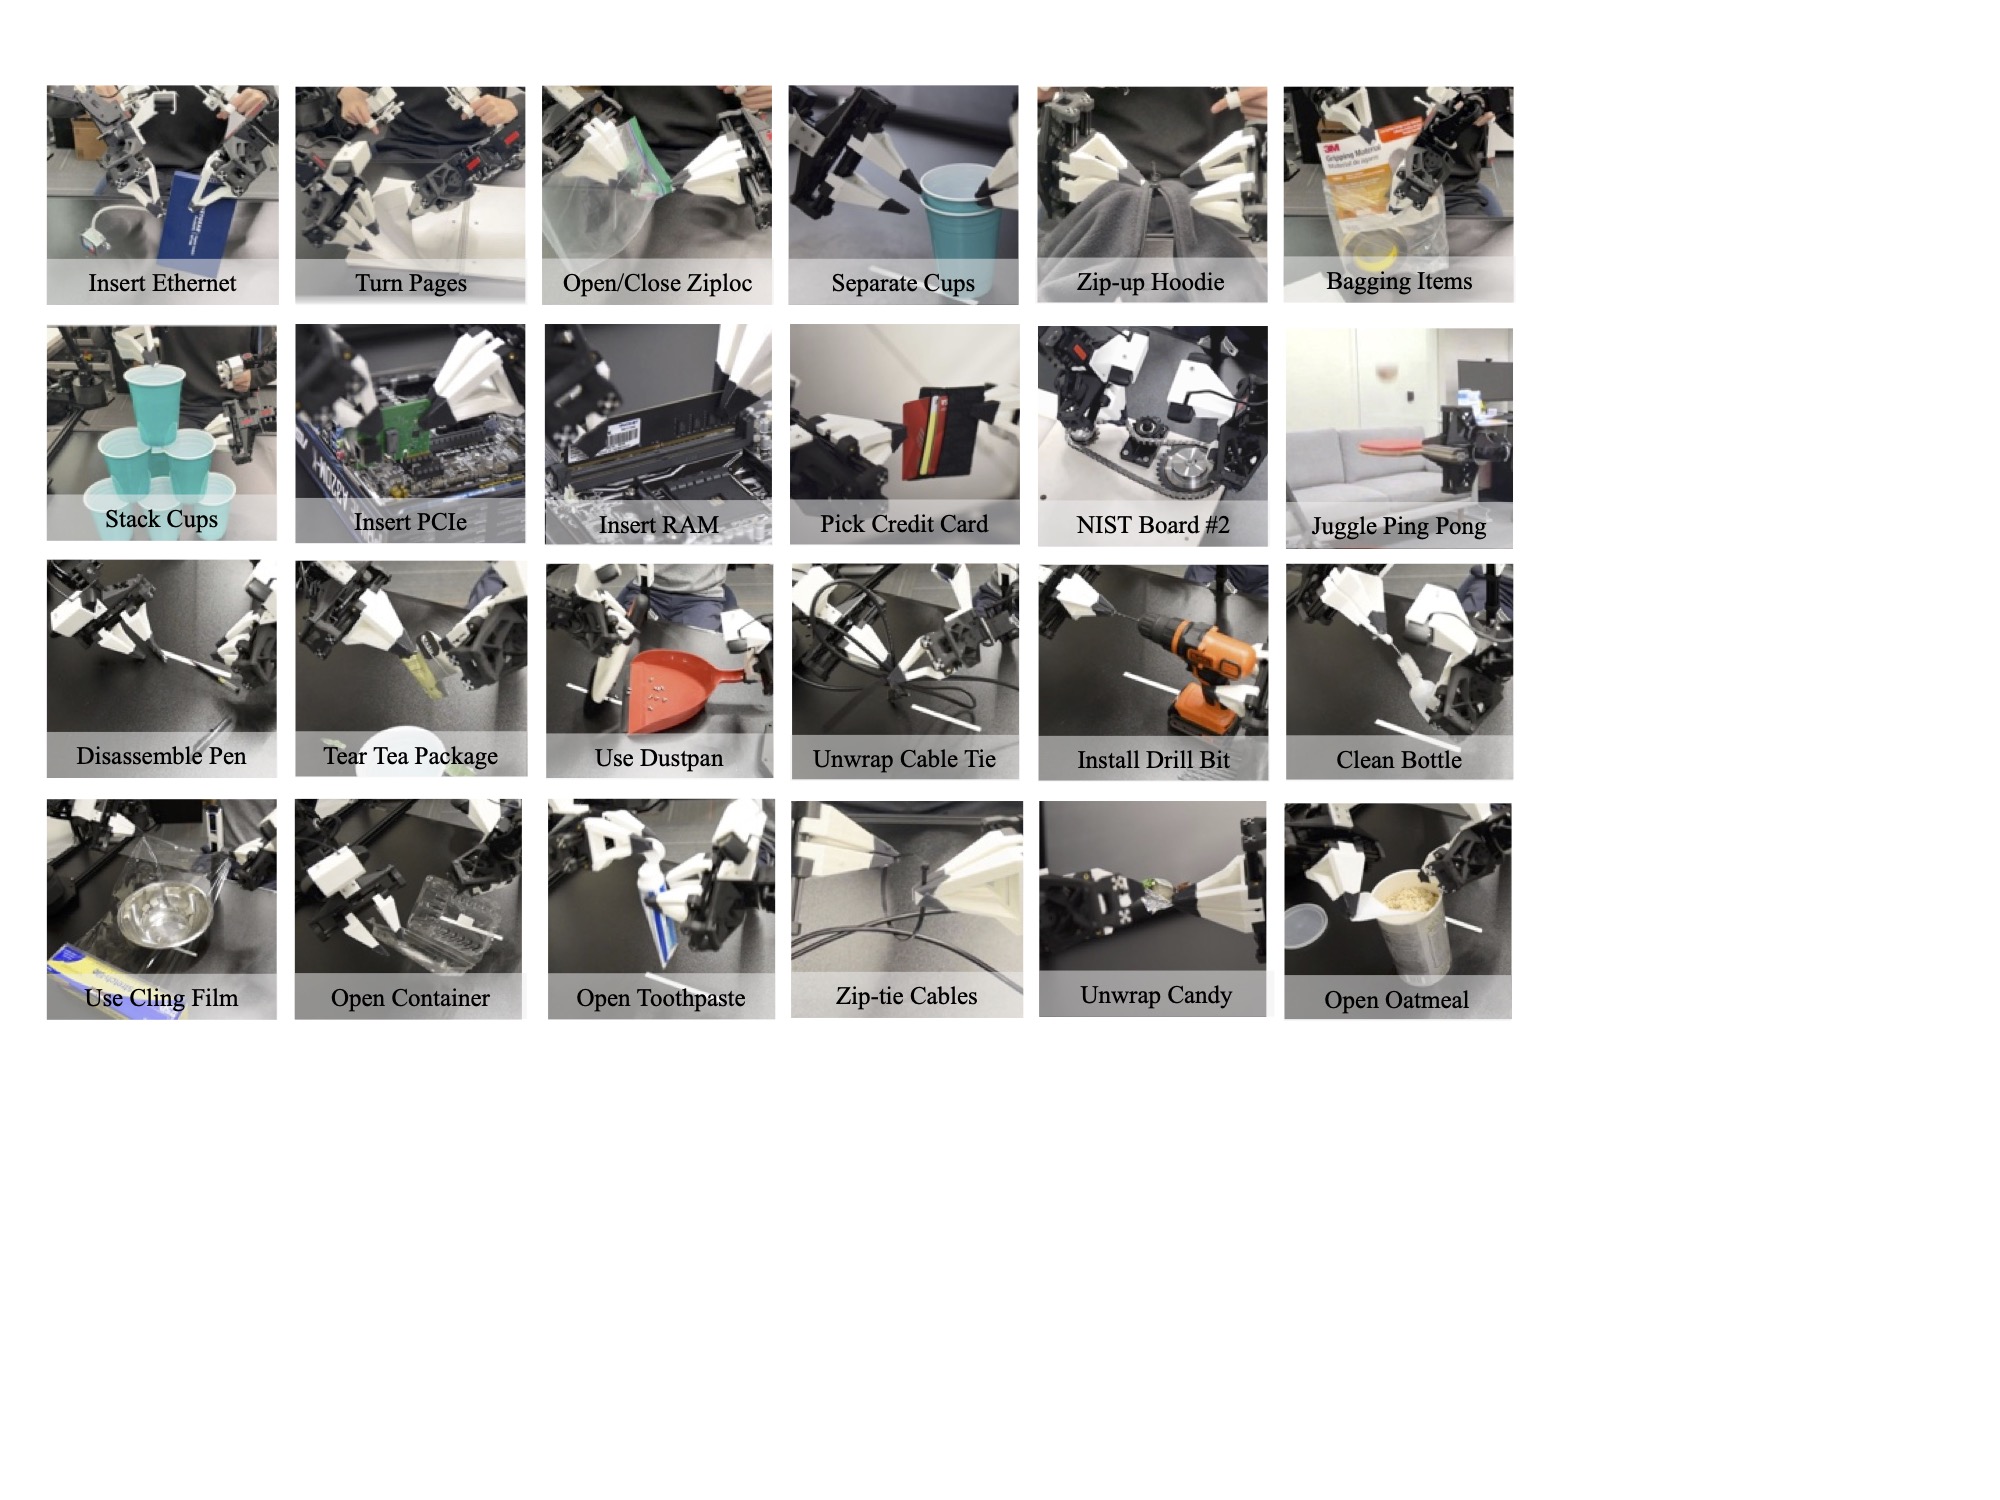
A cross-embodiment imitation learning framework built around a handheld gripper. The tool collects human demonstrations and transfers learned manipulation skills to different robots.
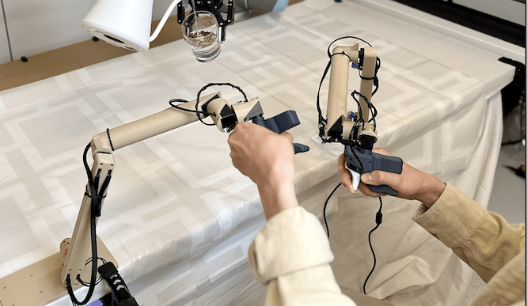
GELLO
Developed by: University of California Berkeley
A General, Low-Cost, and Intuitive Teleoperation Framework for Robot Manipulators
Mobile Manipulators
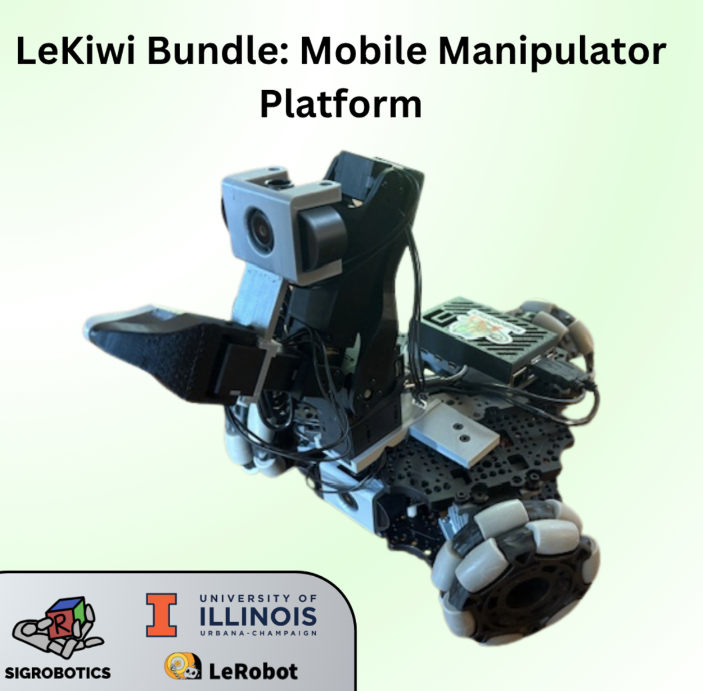
LeKiwi-DYNAMIXEL
Developed by: SIG Robotics team at the University of Illinois Urbana-Champaign
LeKiwi - Low-Cost Mobile Manipulator (DYNAMIXEL Edition)
Social & Bio-inspired Robots
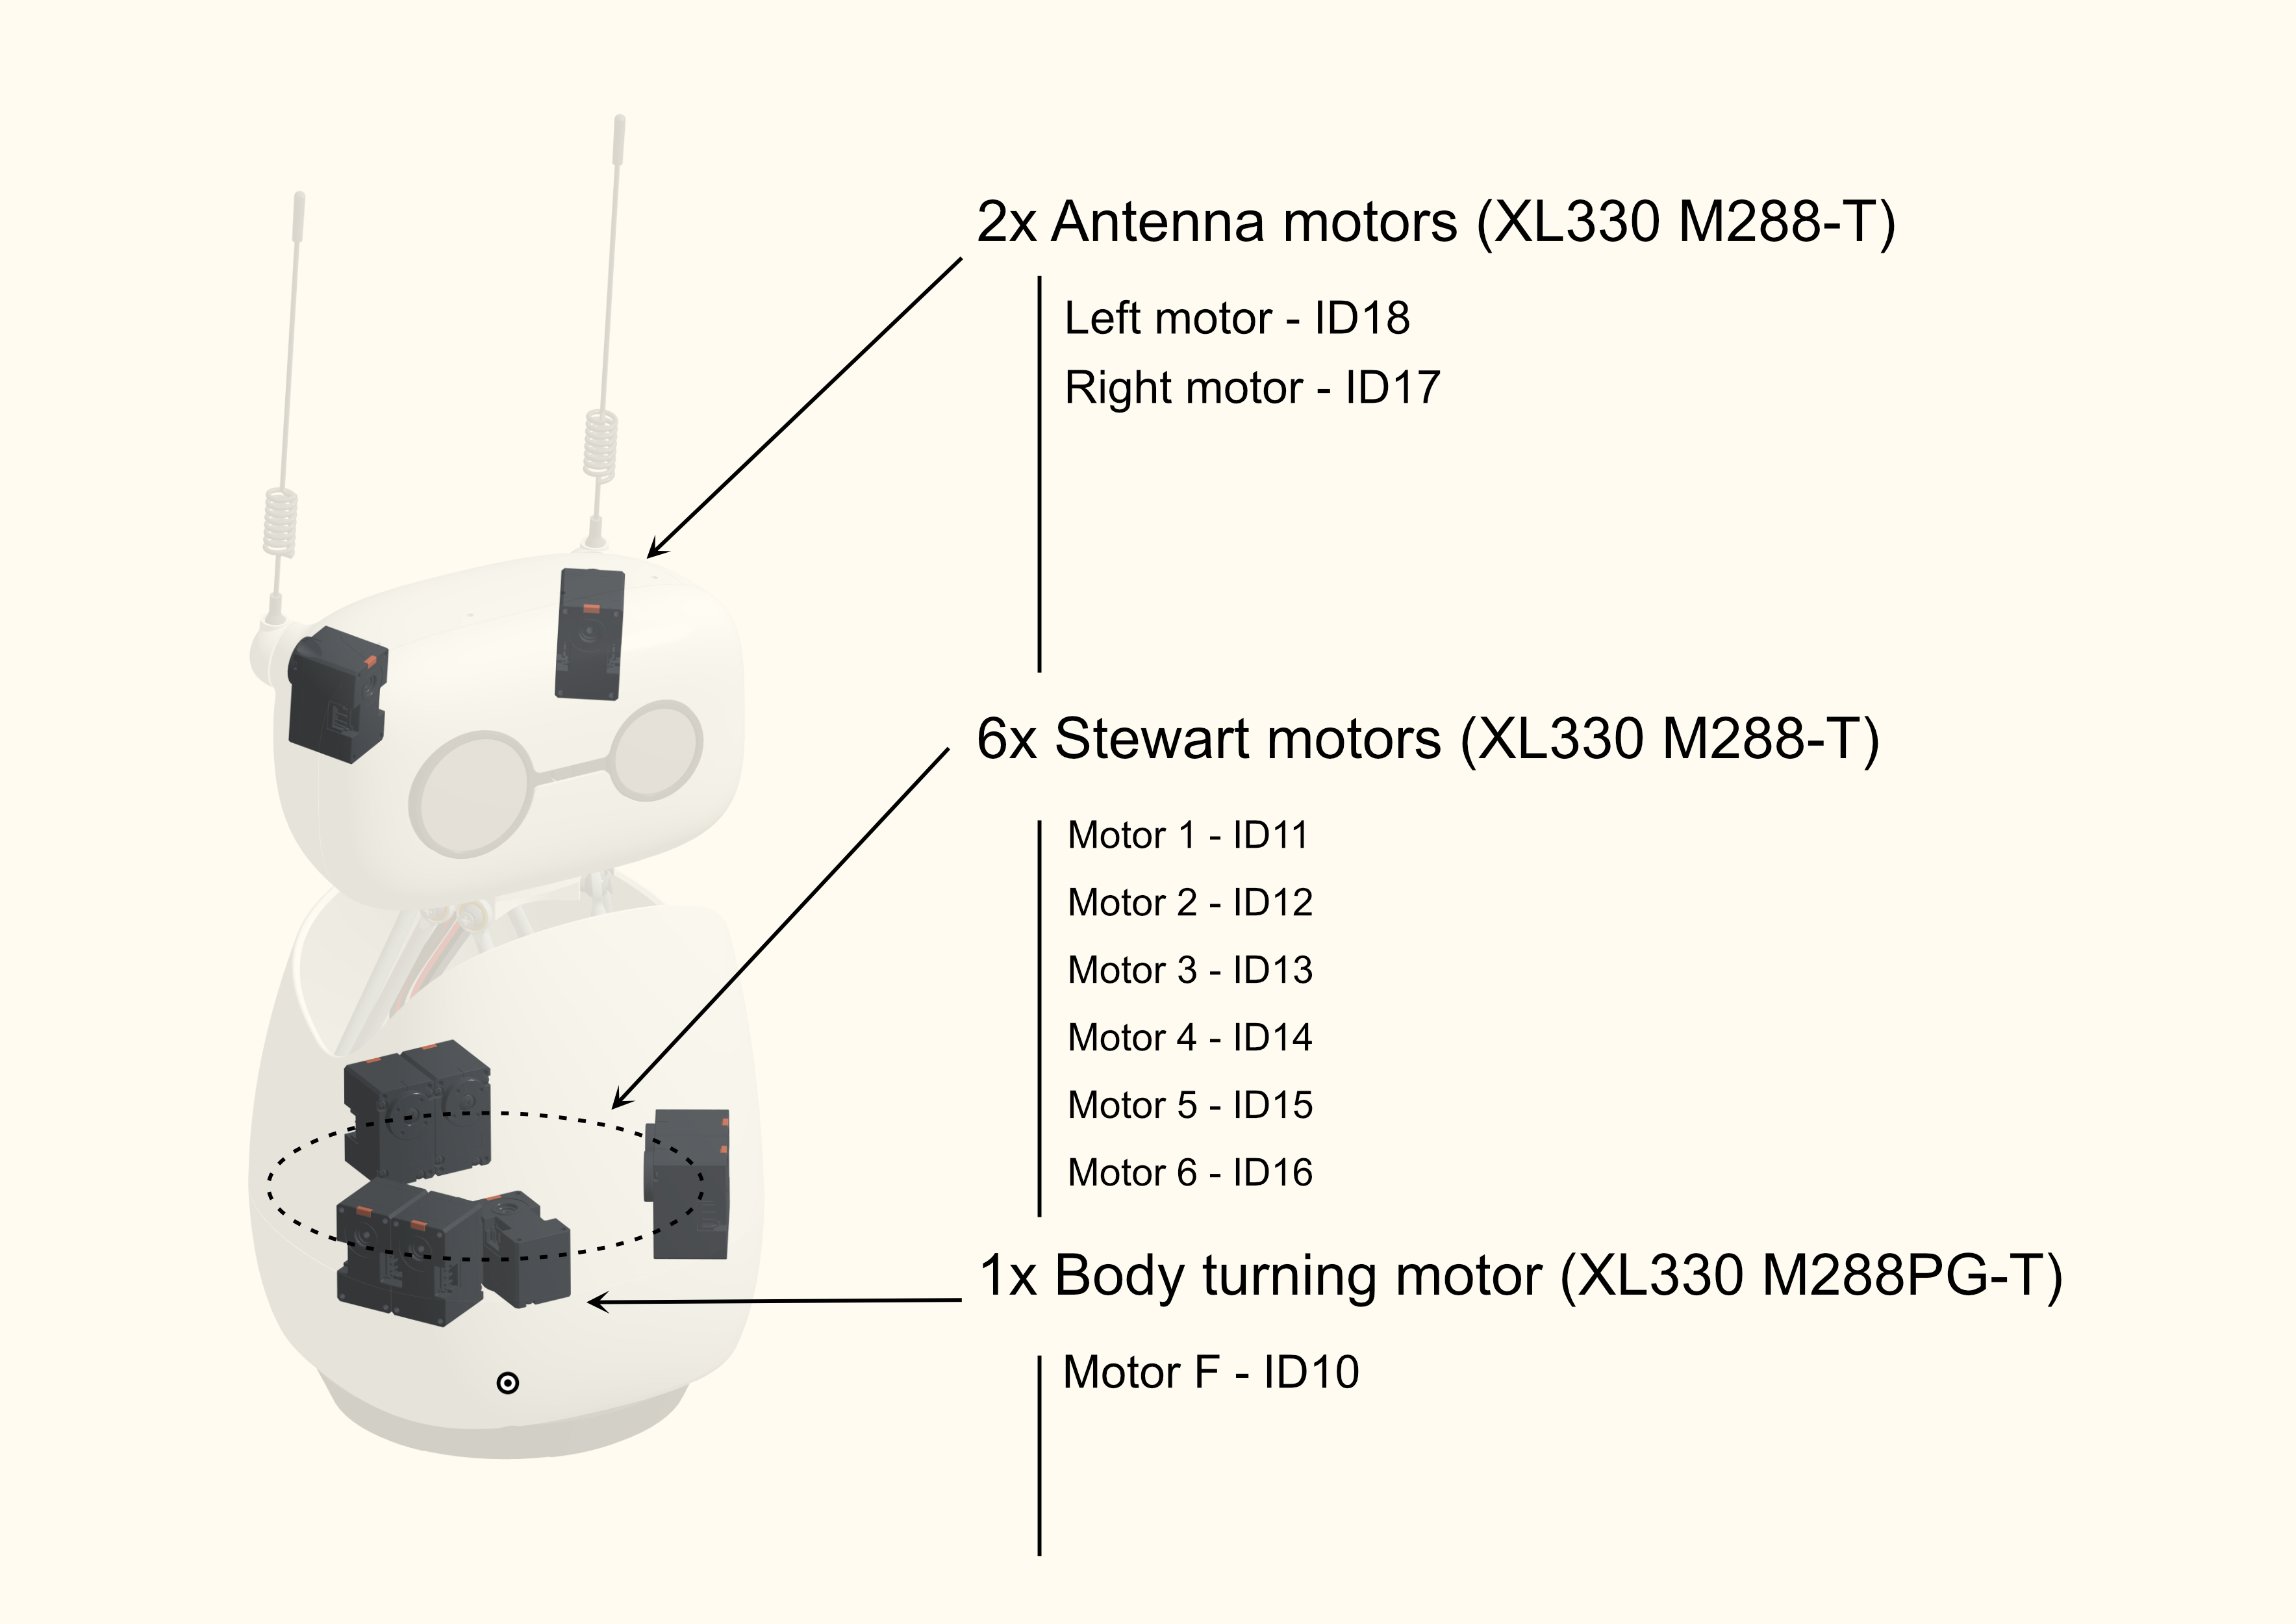
Reachy-Mini
Developed by: Pollen Robotics
Reachy-Mini is a small, agile, and versatile robot designed for research and education in robotics. It uses nine DYNAMIXEL XL330-M288-T actuators.
Share Your Project!
The DYNAMIXEL community is a vibrant hub of innovation. If you have an open-source project that utilizes DYNAMIXEL actuators, we'd love to hear about it and potentially feature it here!
Your Idea, Powered by DYNAMIXEL. Let's build the future together.